Selected work
1 / 4
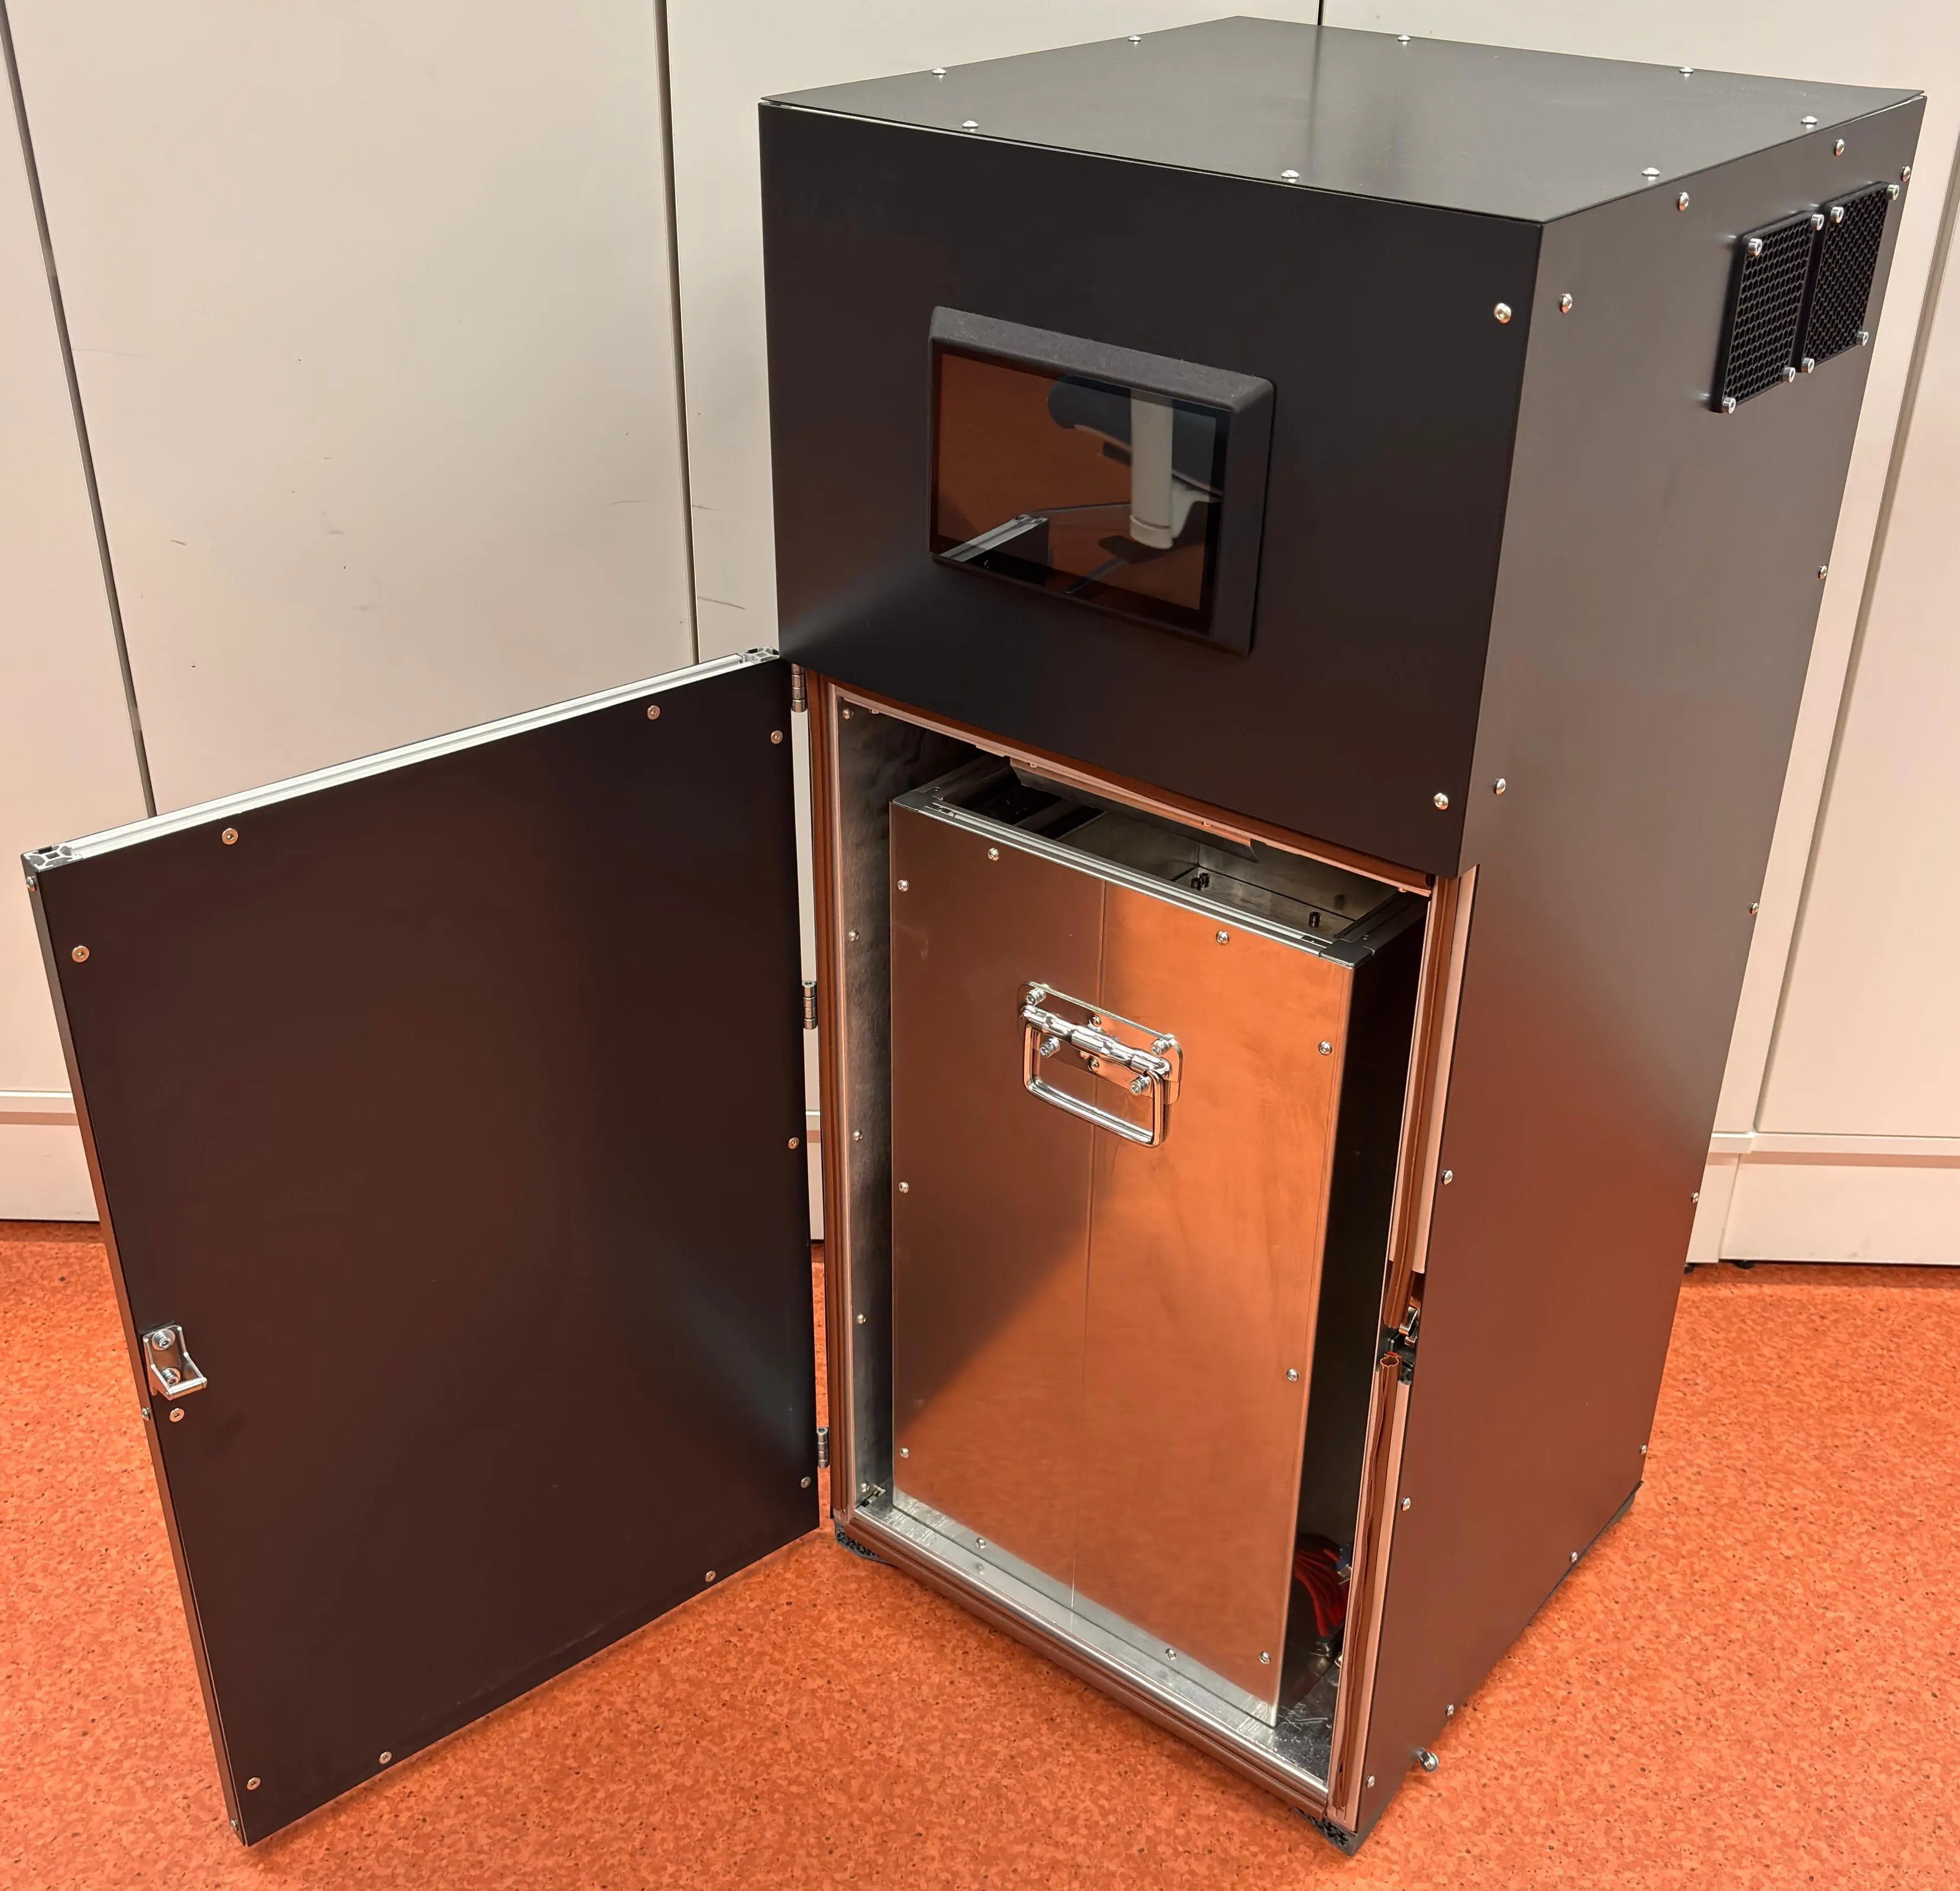
SLS 3D Printer
2025-26I designed and manufactured the complete mechanical system for a compact selective laser sintering printer. It has a 195 × 195 × 240 mm build volume inside a 412 × 412 × 912 mm machine: more build volume than a Formlabs Fuse 1+, in a smaller footprint. Chamber heating is split across eight zones, and a control loop reading an IR camera holds the powder surface at temperature. A 450 nm laser diode sinters the powder, scanned by a galvo and f-theta lens. Built at an additive manufacturing company I cofounded, which has raised €100,000 in funding so far.
1 / 4
Omniball Holonomic Motion Base
2024My bachelor's thesis: an open-source holonomic drive platform for assistive and medical robots. Omniball wheels let it translate in any direction without rotating first, and it carries 65 kg while clearing everyday obstacles like door sills and floor gaps. Almost every part is 3D printed, so it can be replicated cheaply.
1 / 4
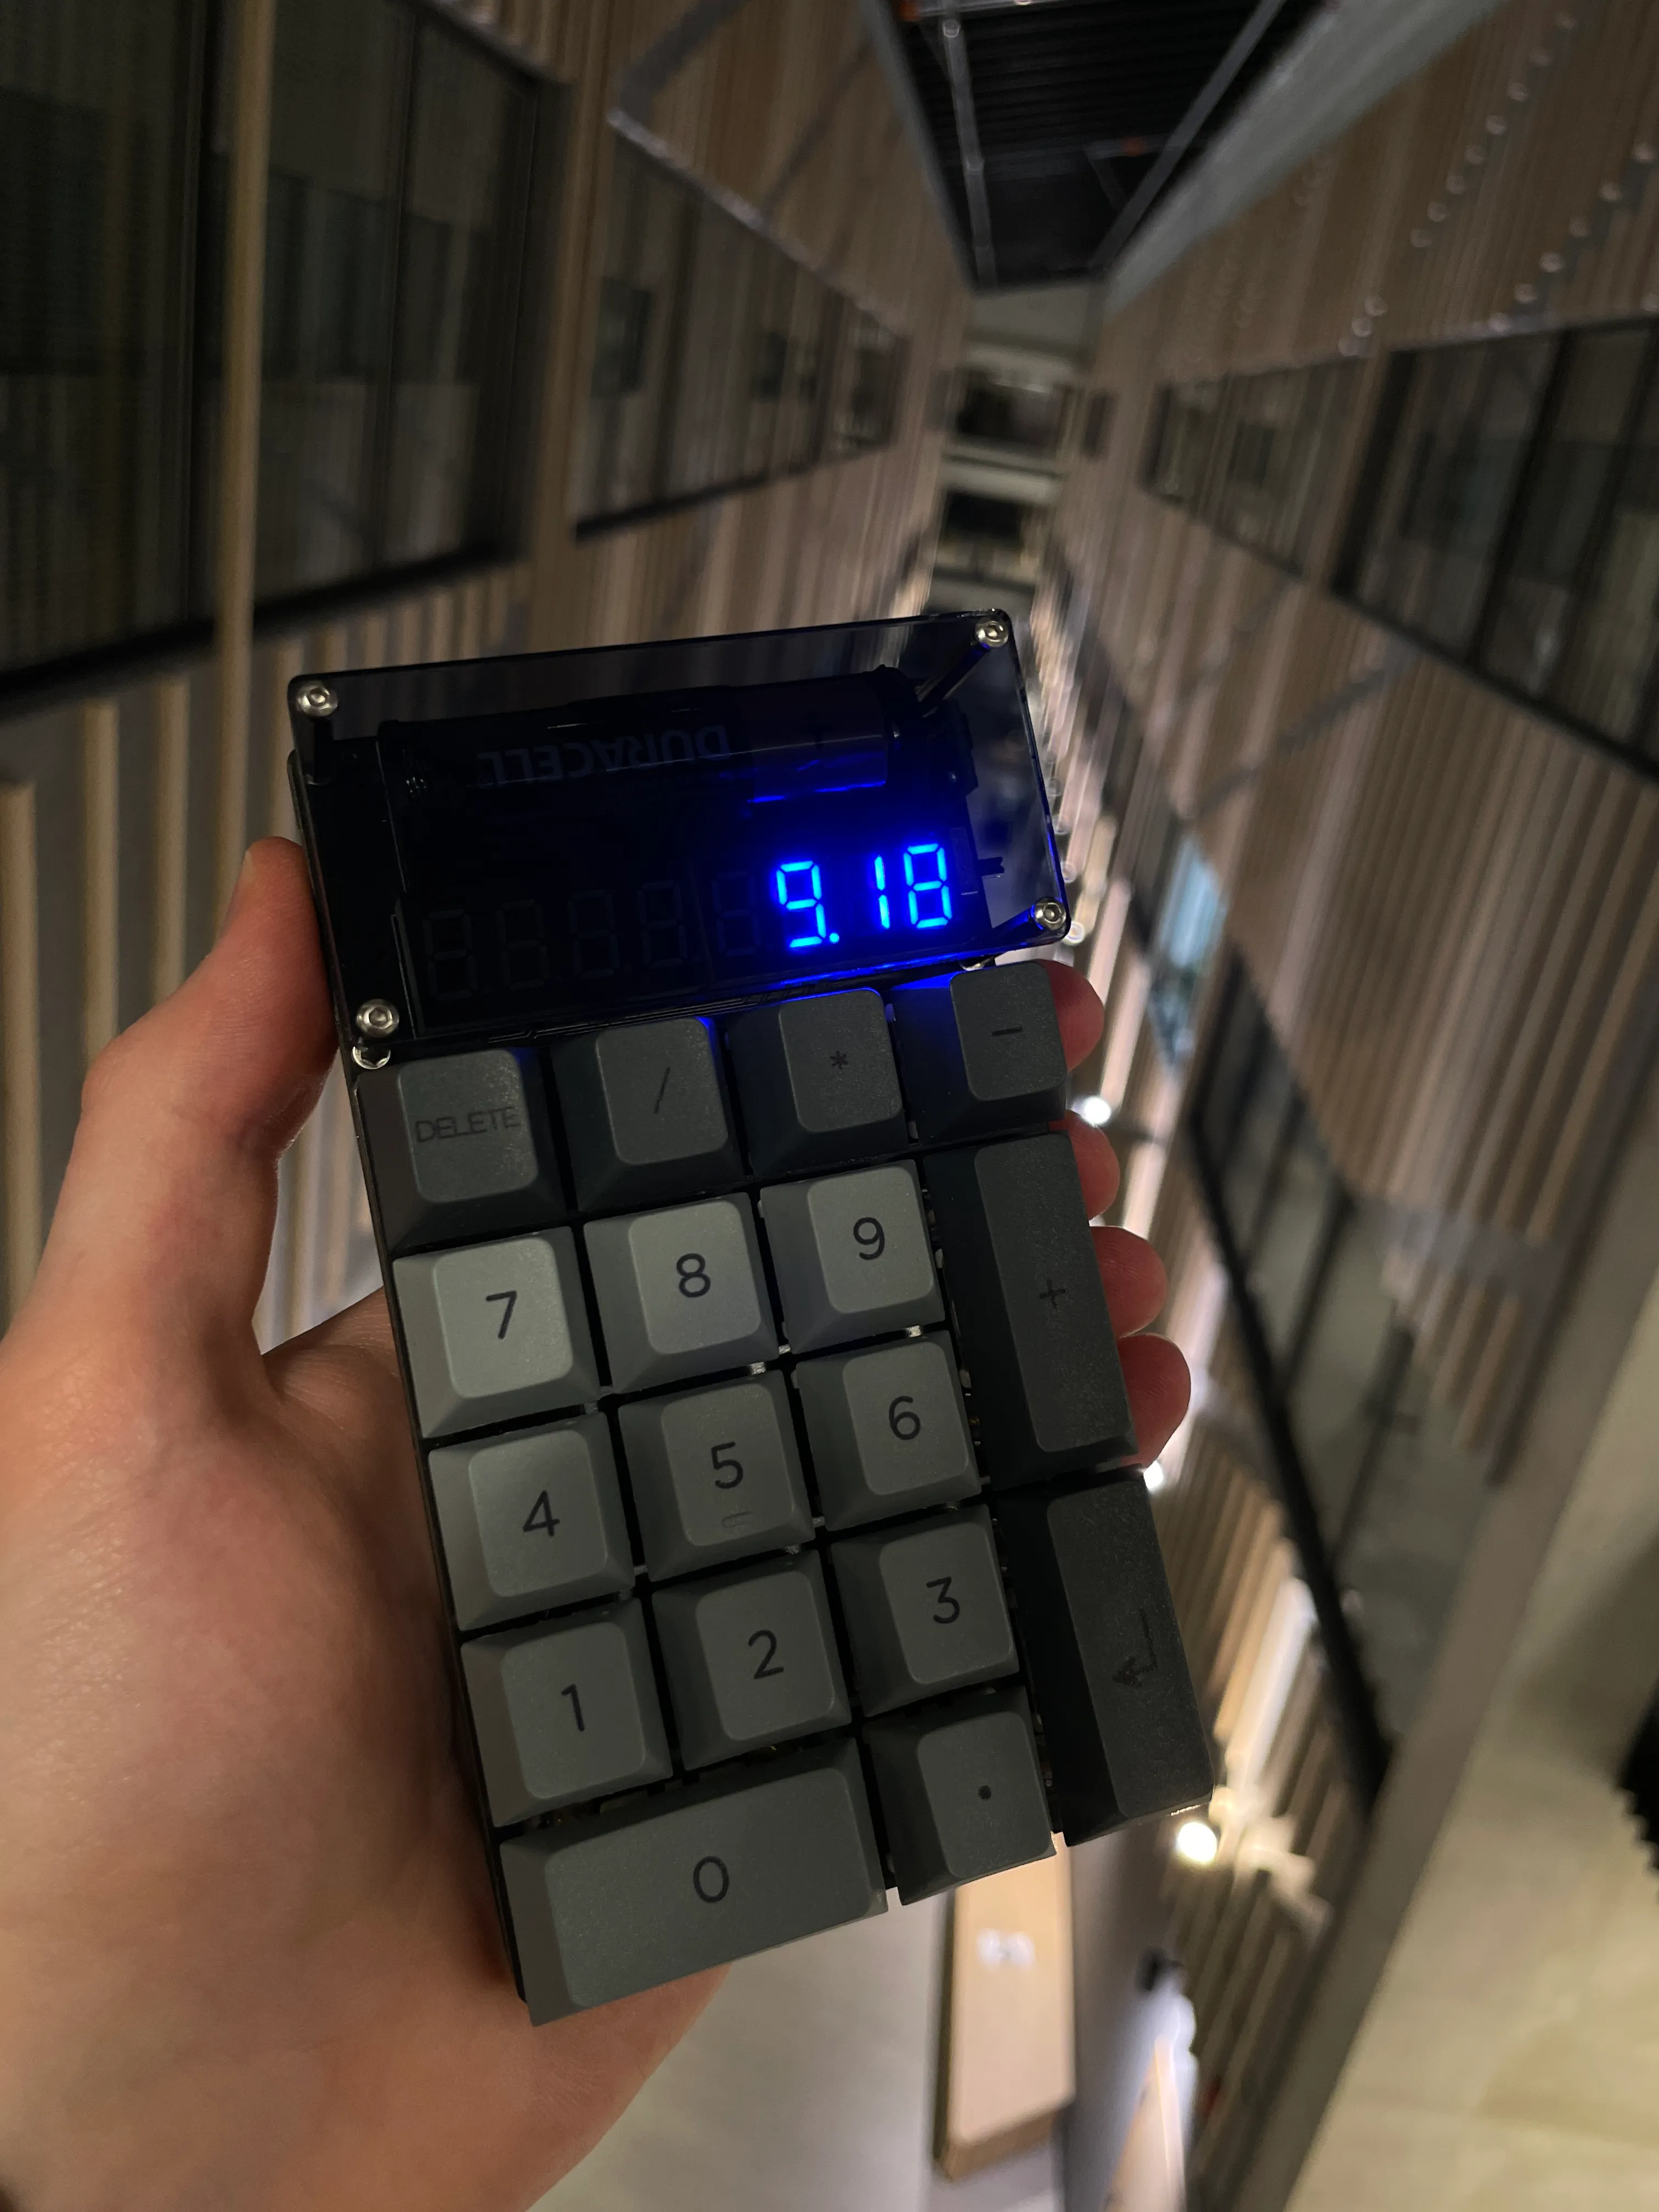
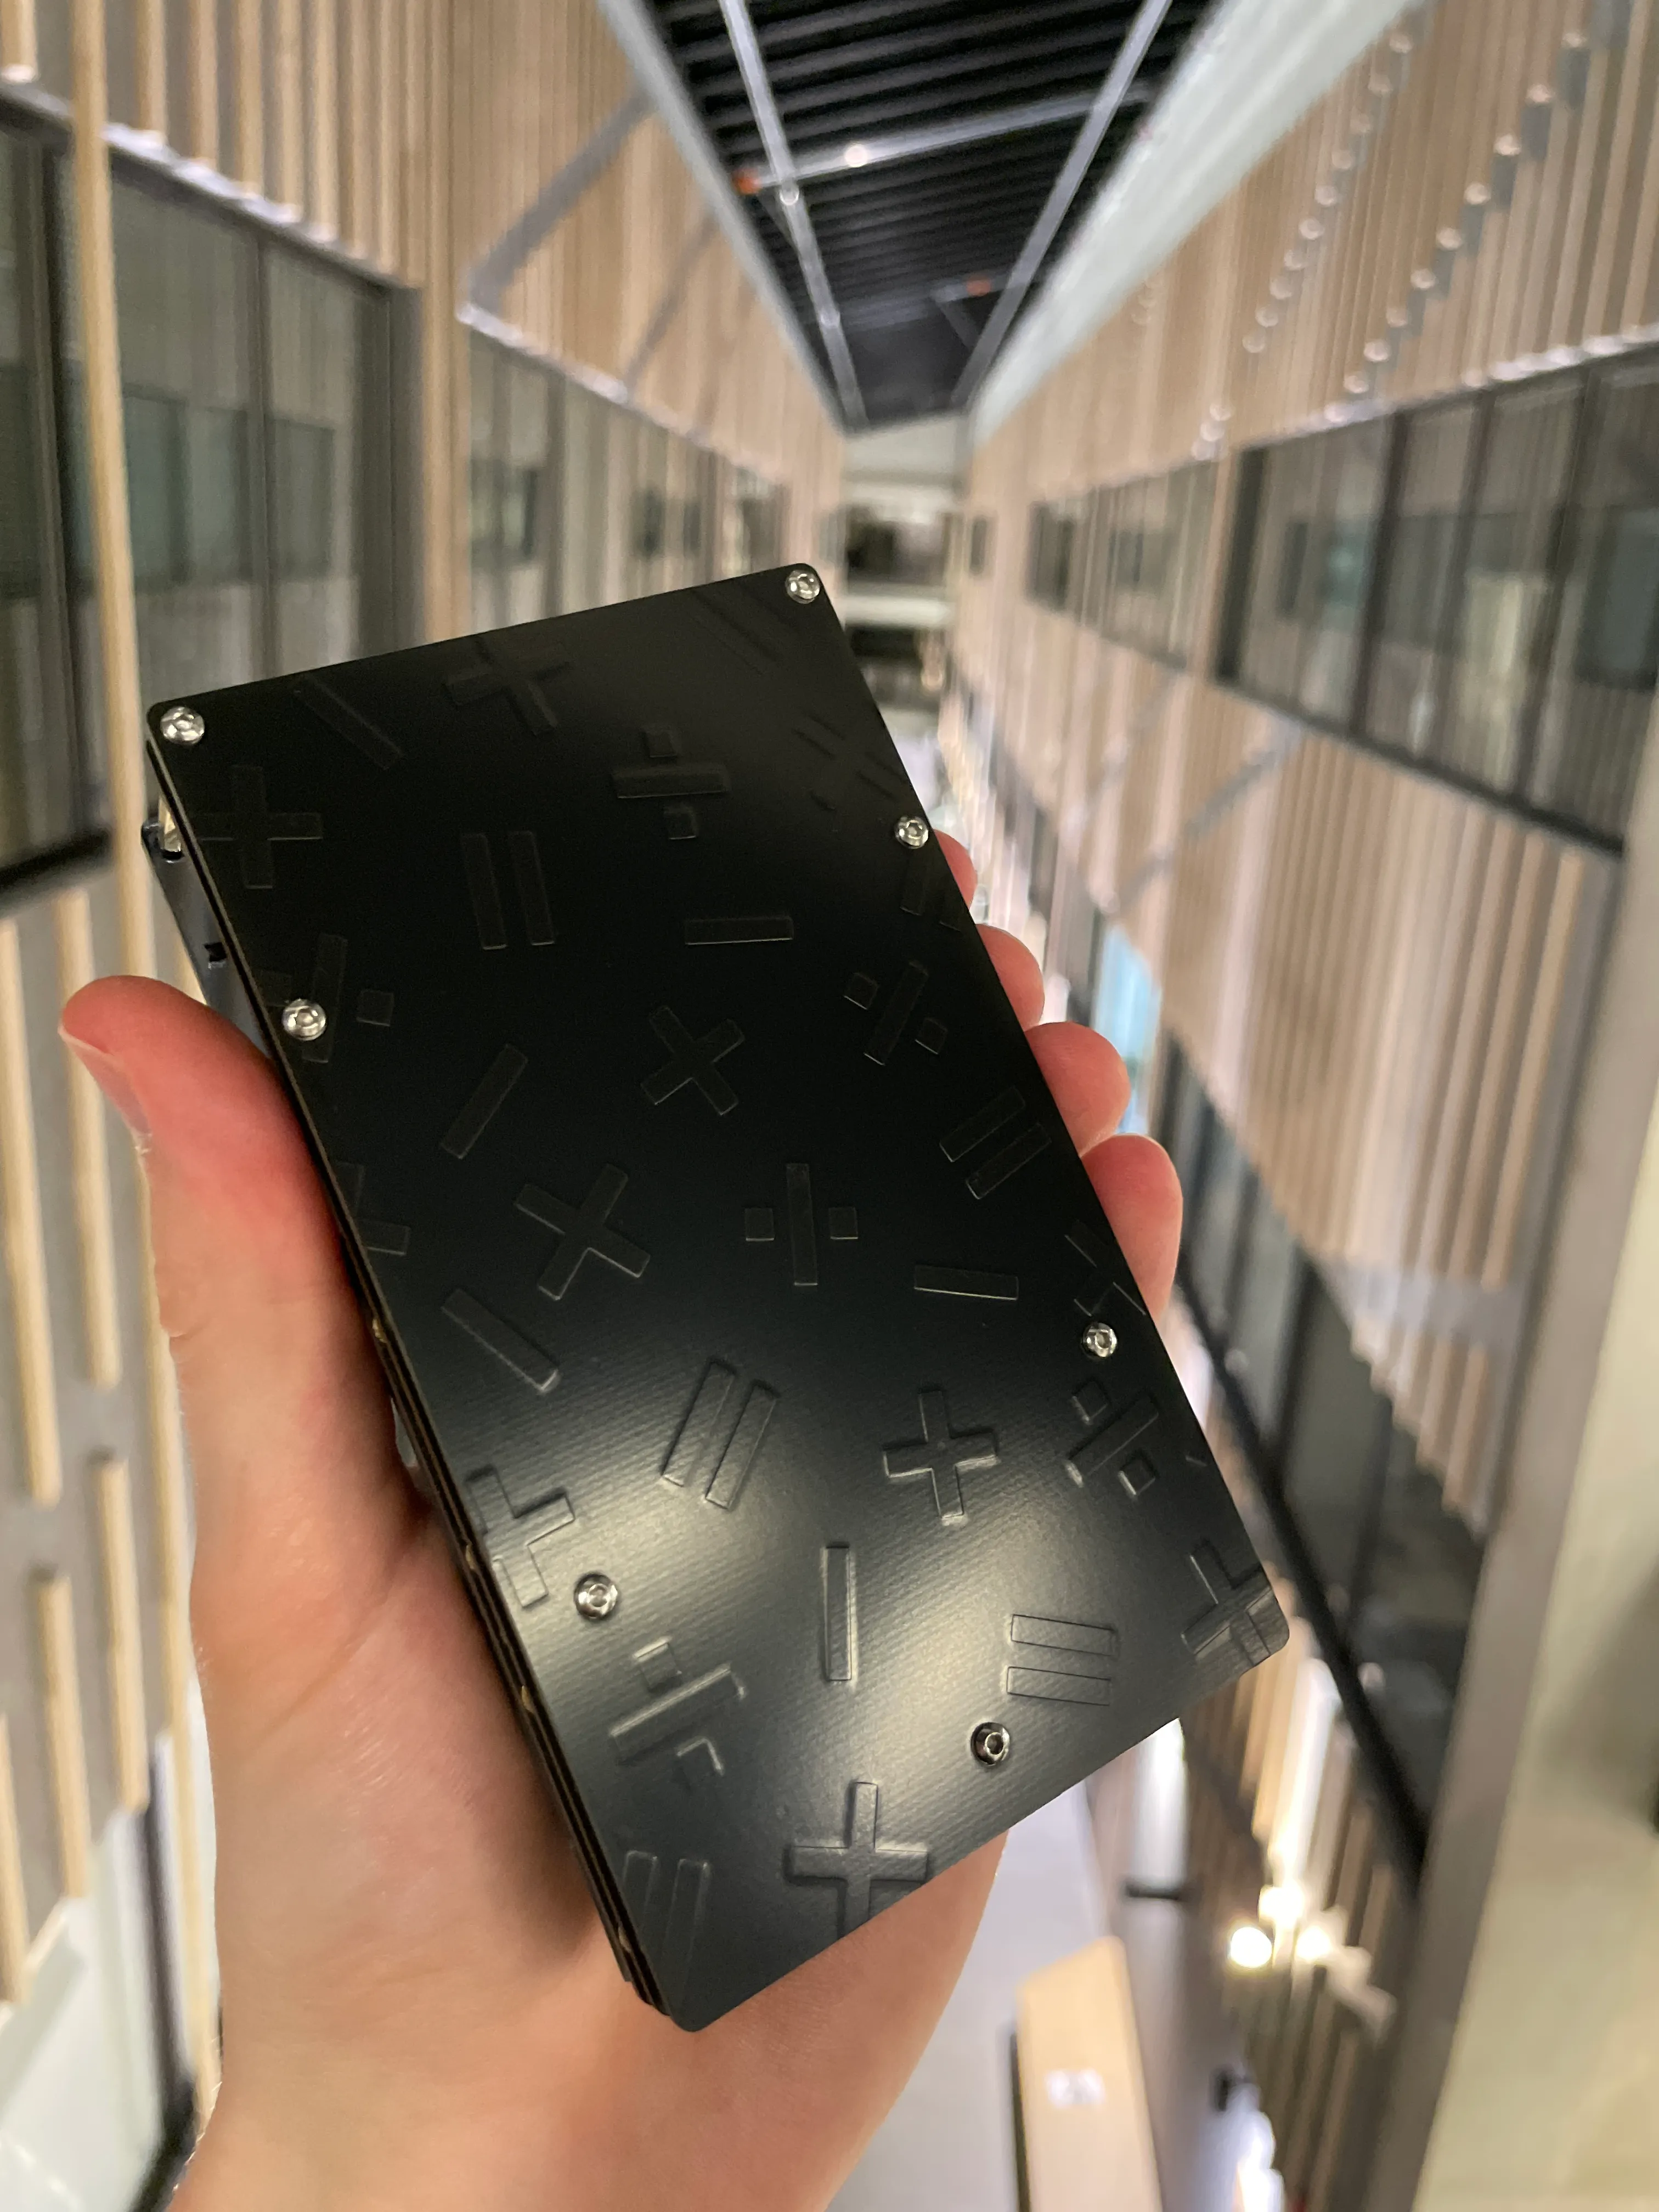
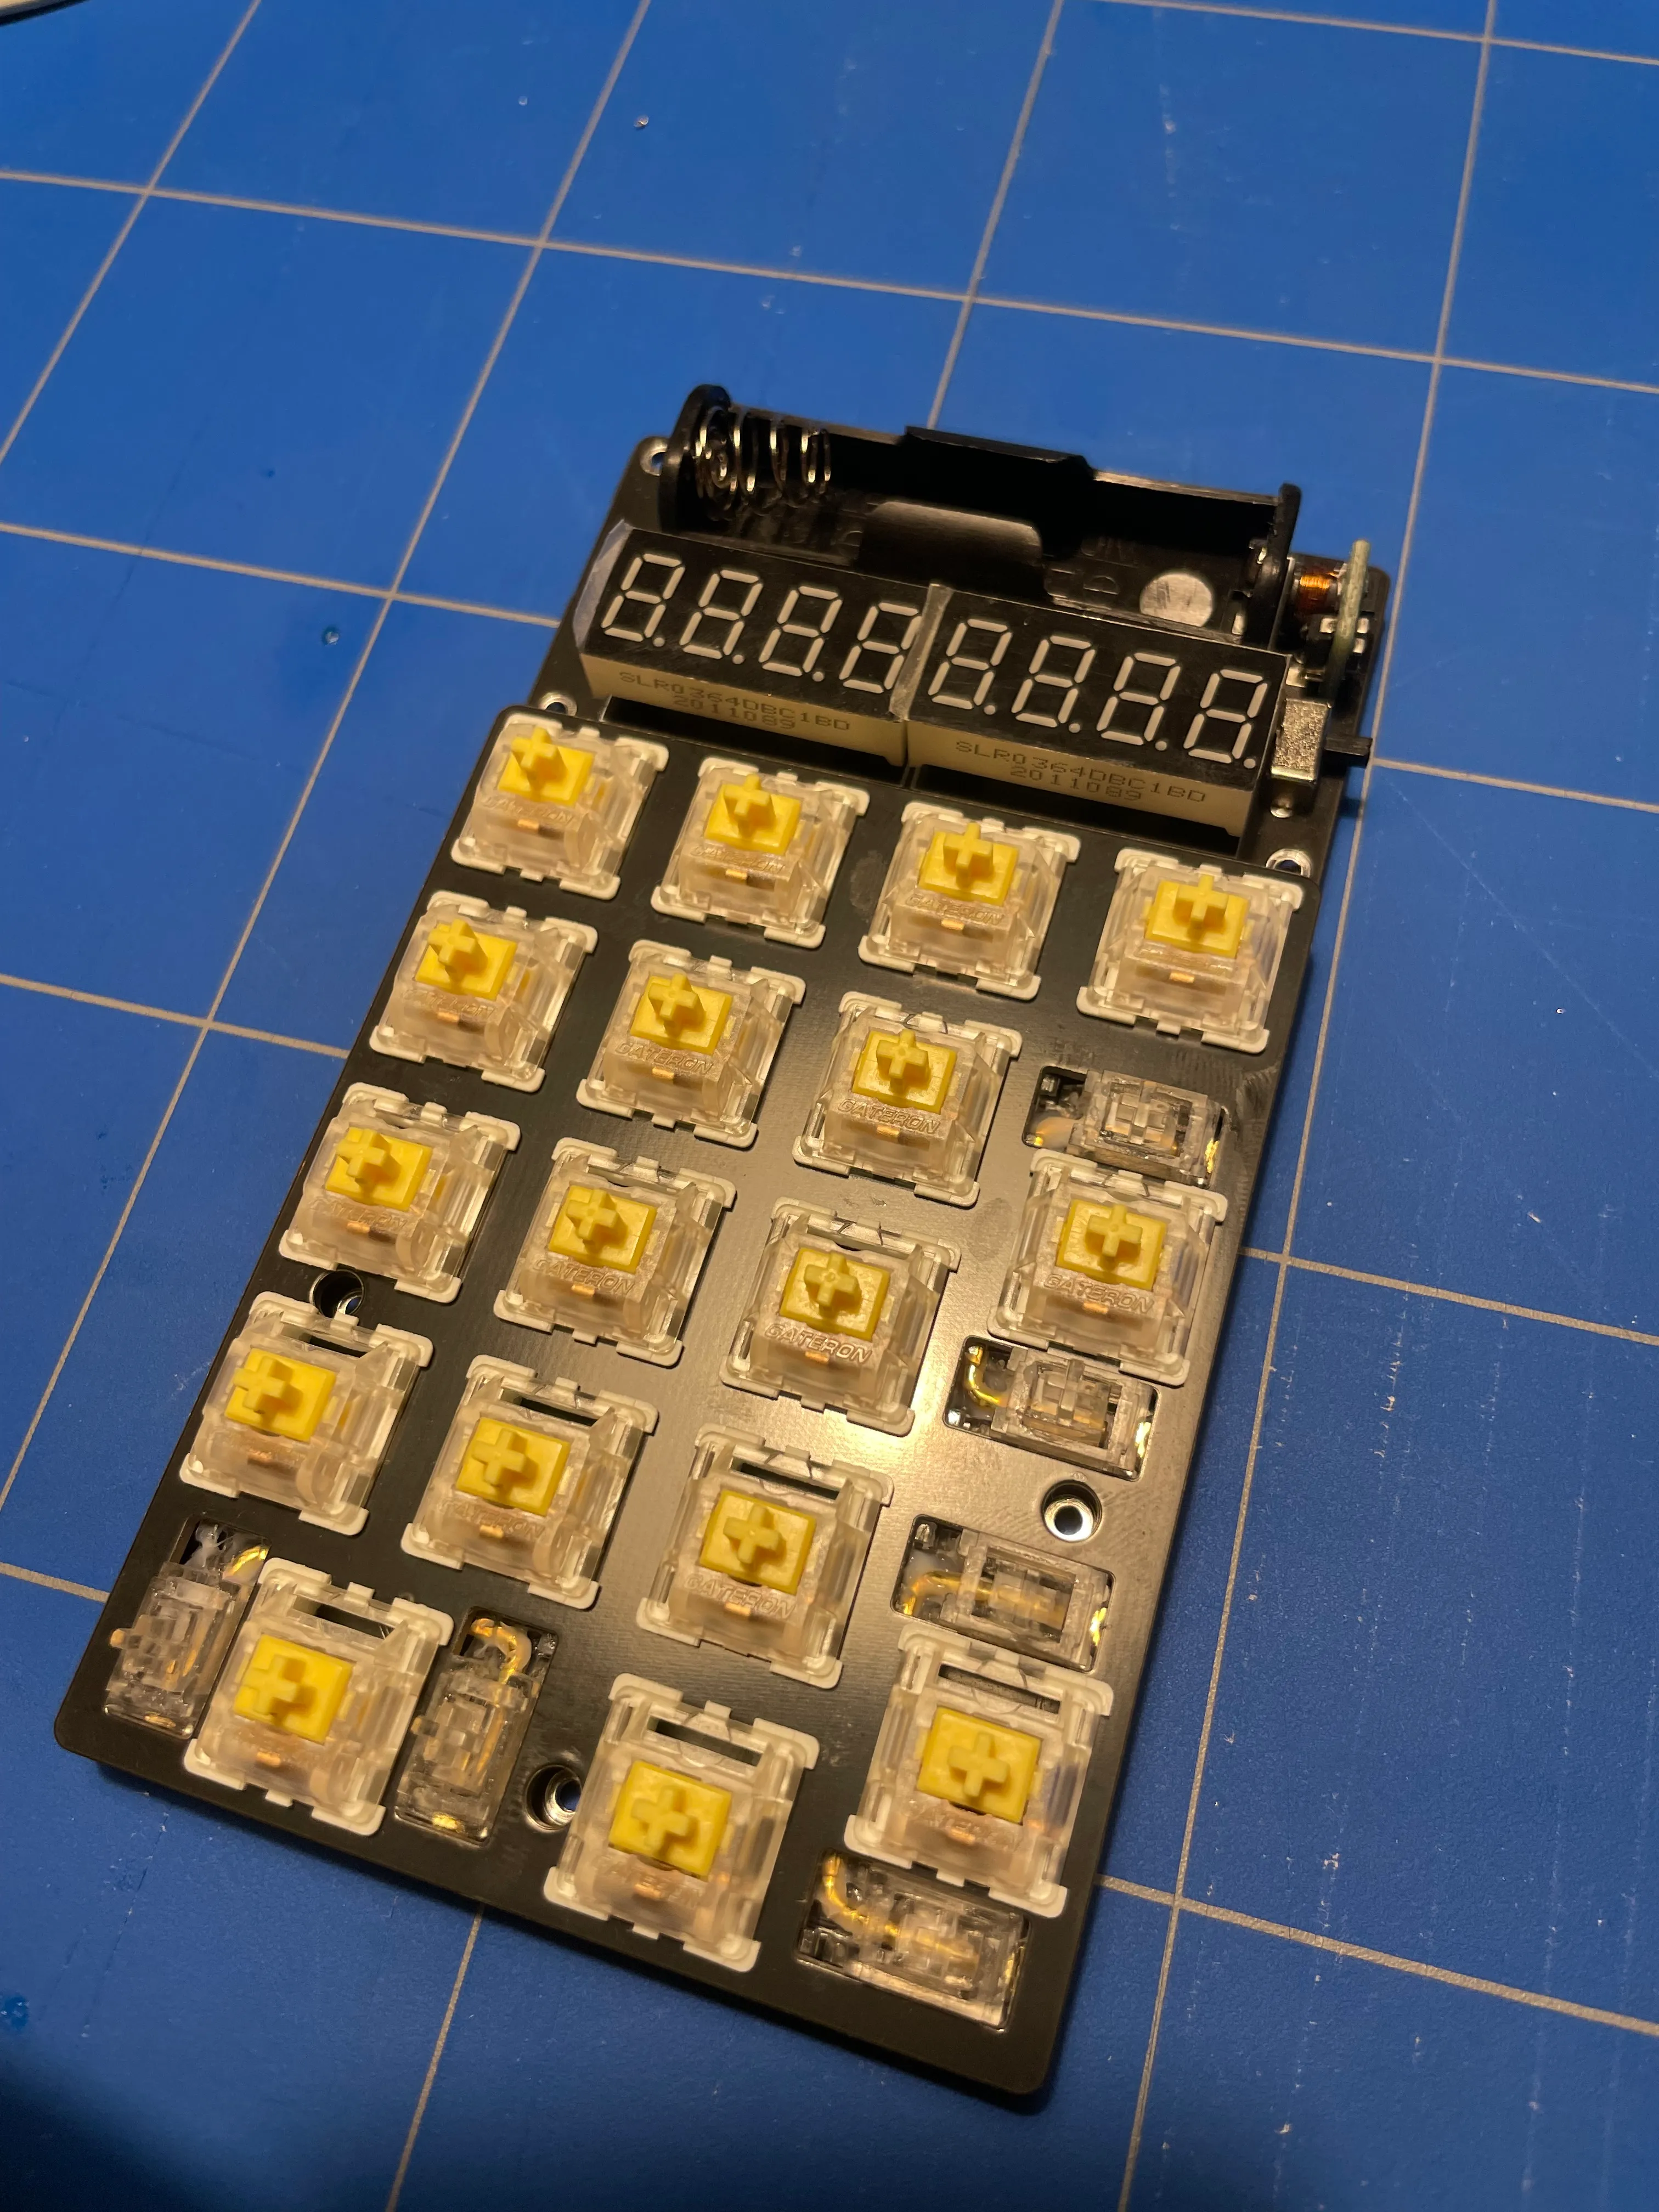
7-Segment Mechanical-Key Calculator
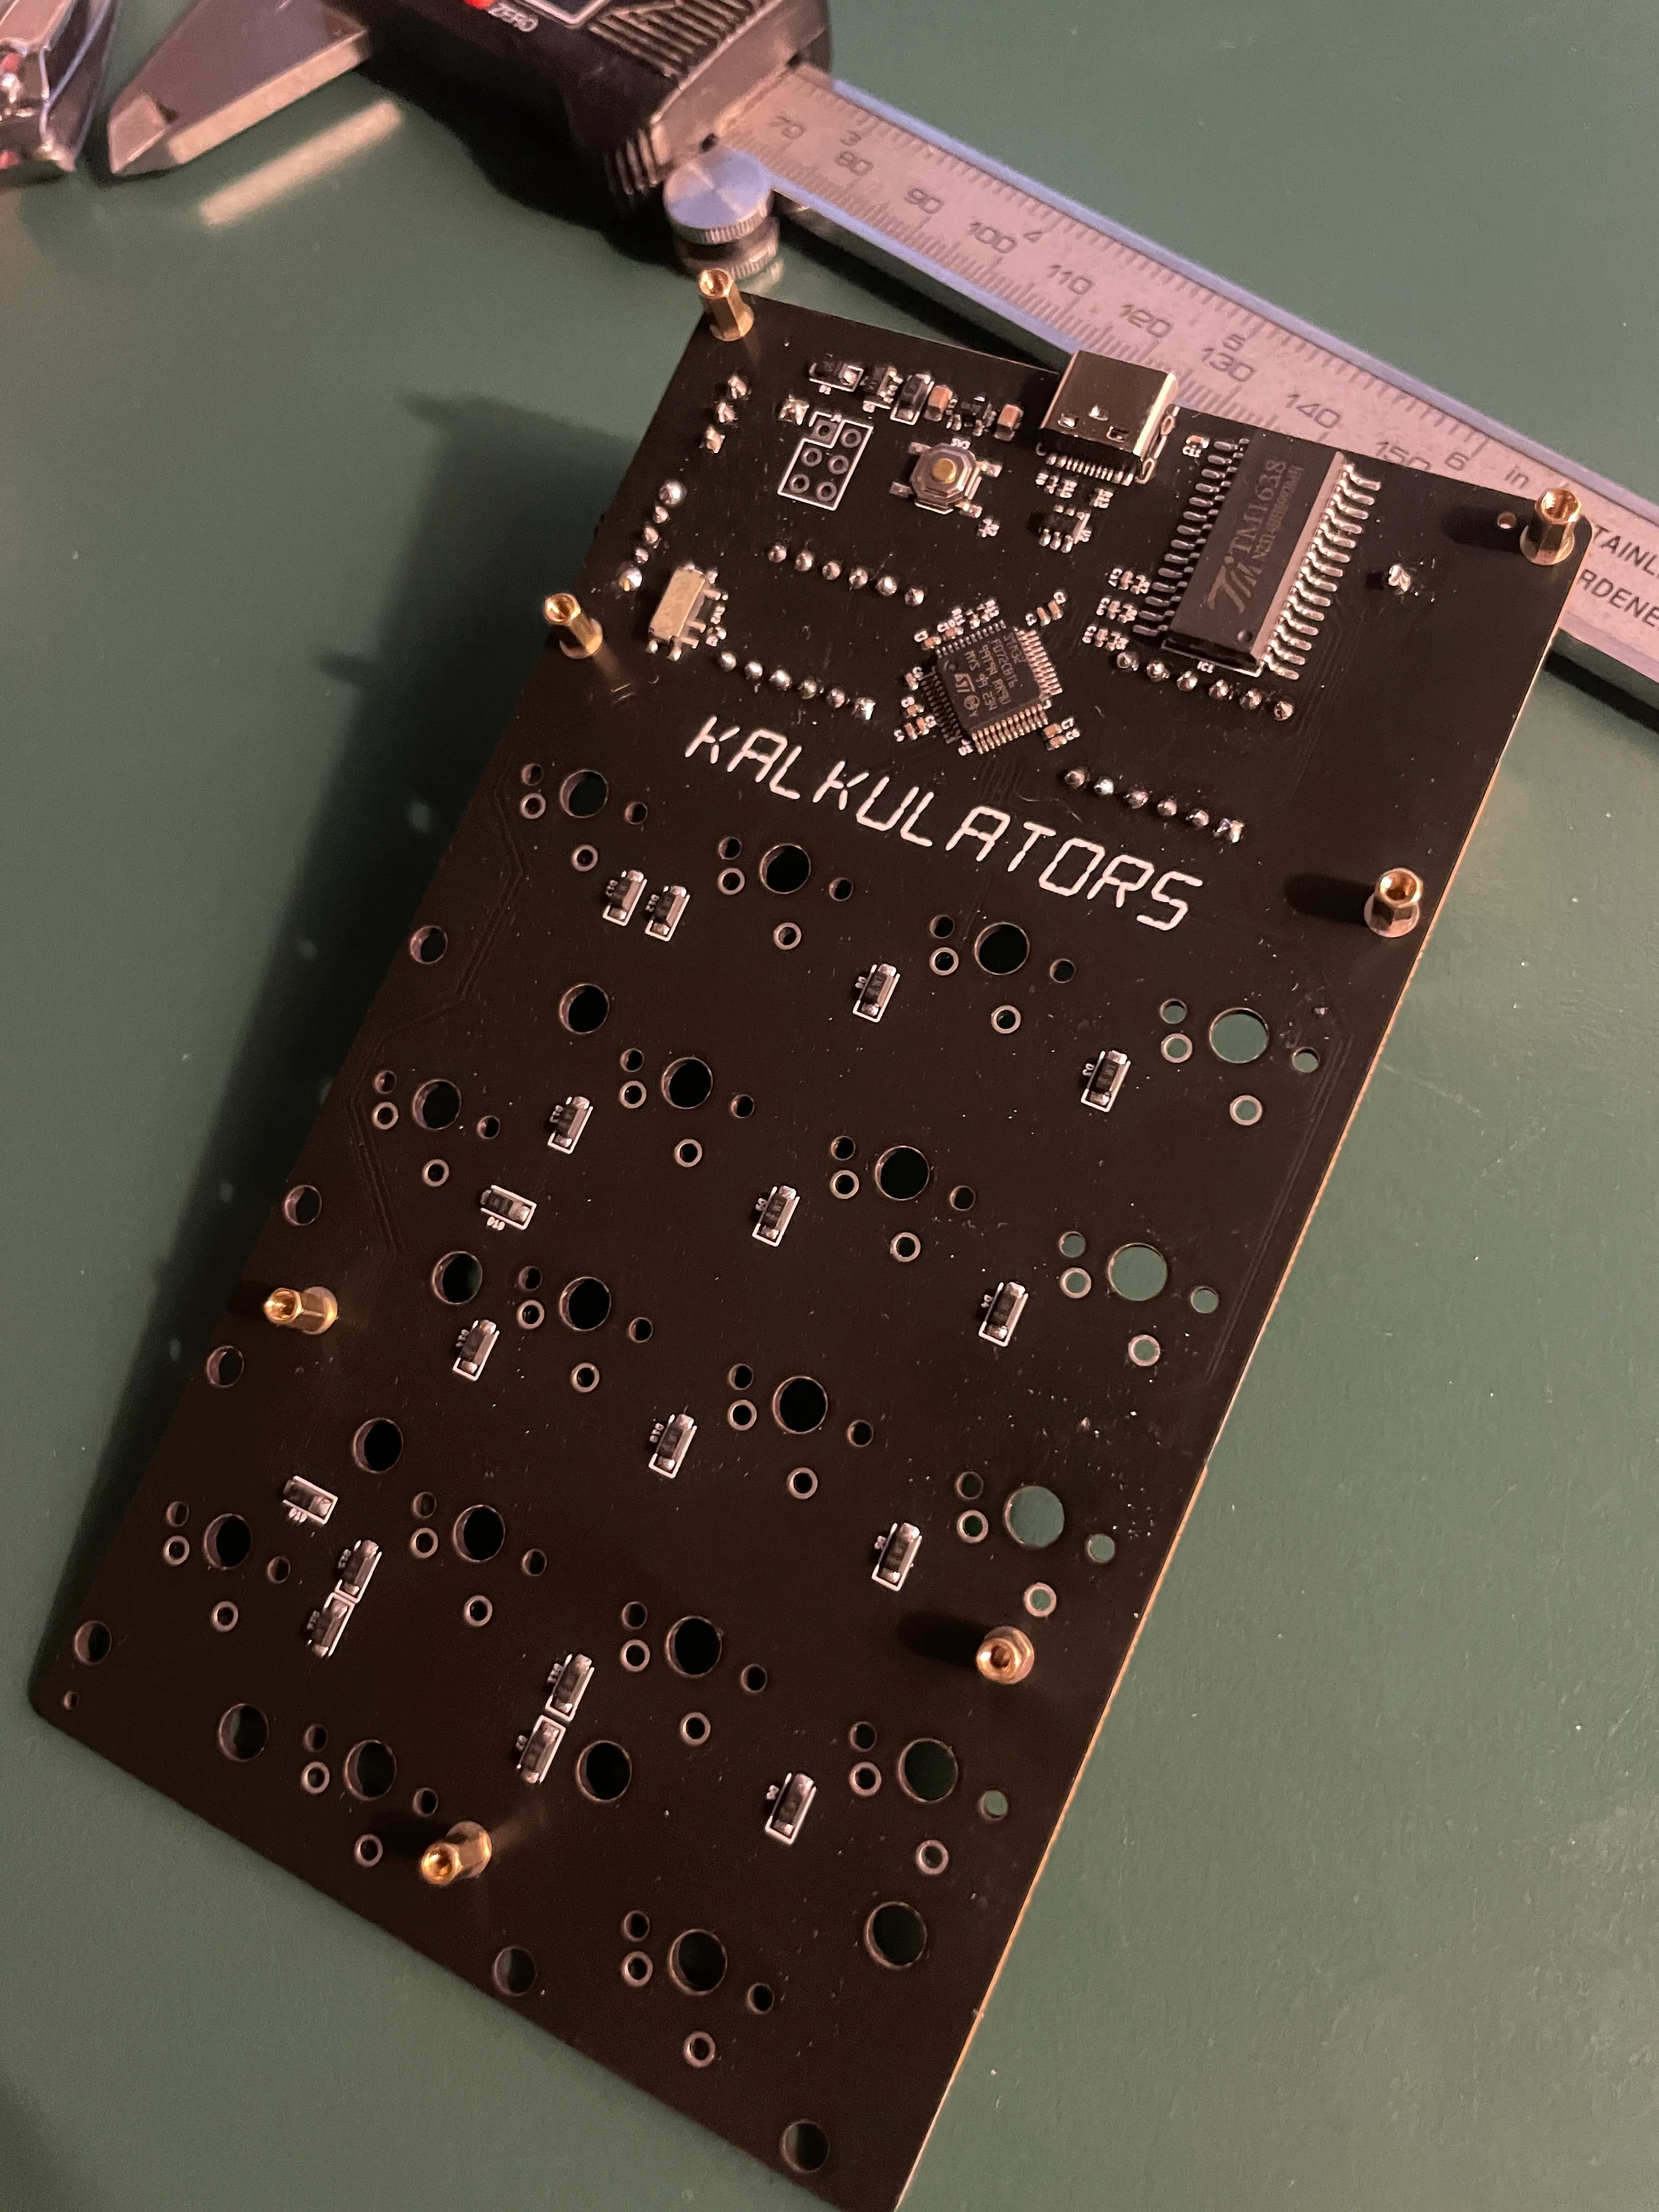
2024I designed a calculator that uses mechanical switches and sold it as a kit. It runs QMK on an STM32, with a TM1638 driving the seven-segment display. Standalone it runs off a single AA battery; over USB-C it turns into a numpad or macropad, every key remappable in VIA. Kits have shipped as far as Australia.
1 / 3
Robotont Gen3 Lite
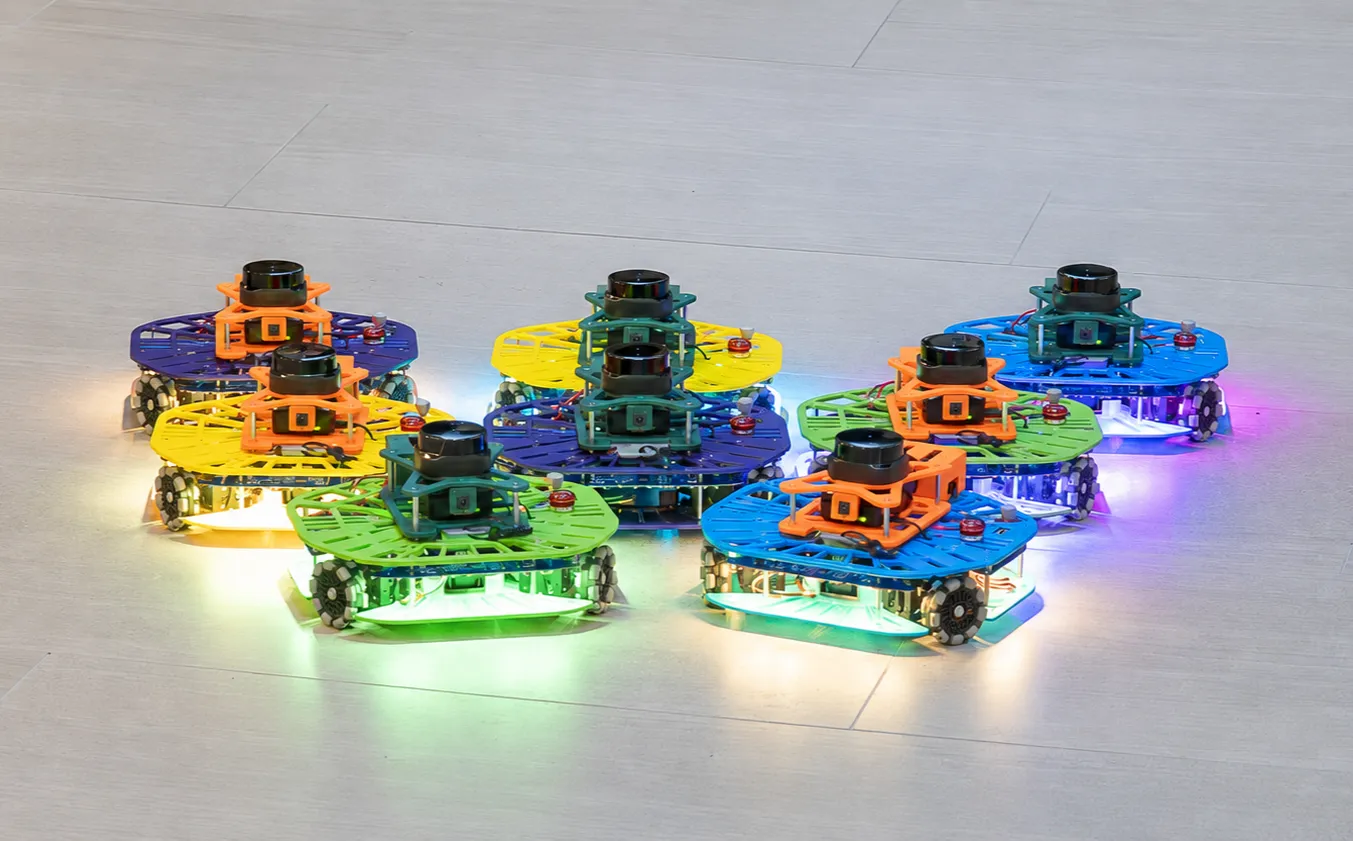
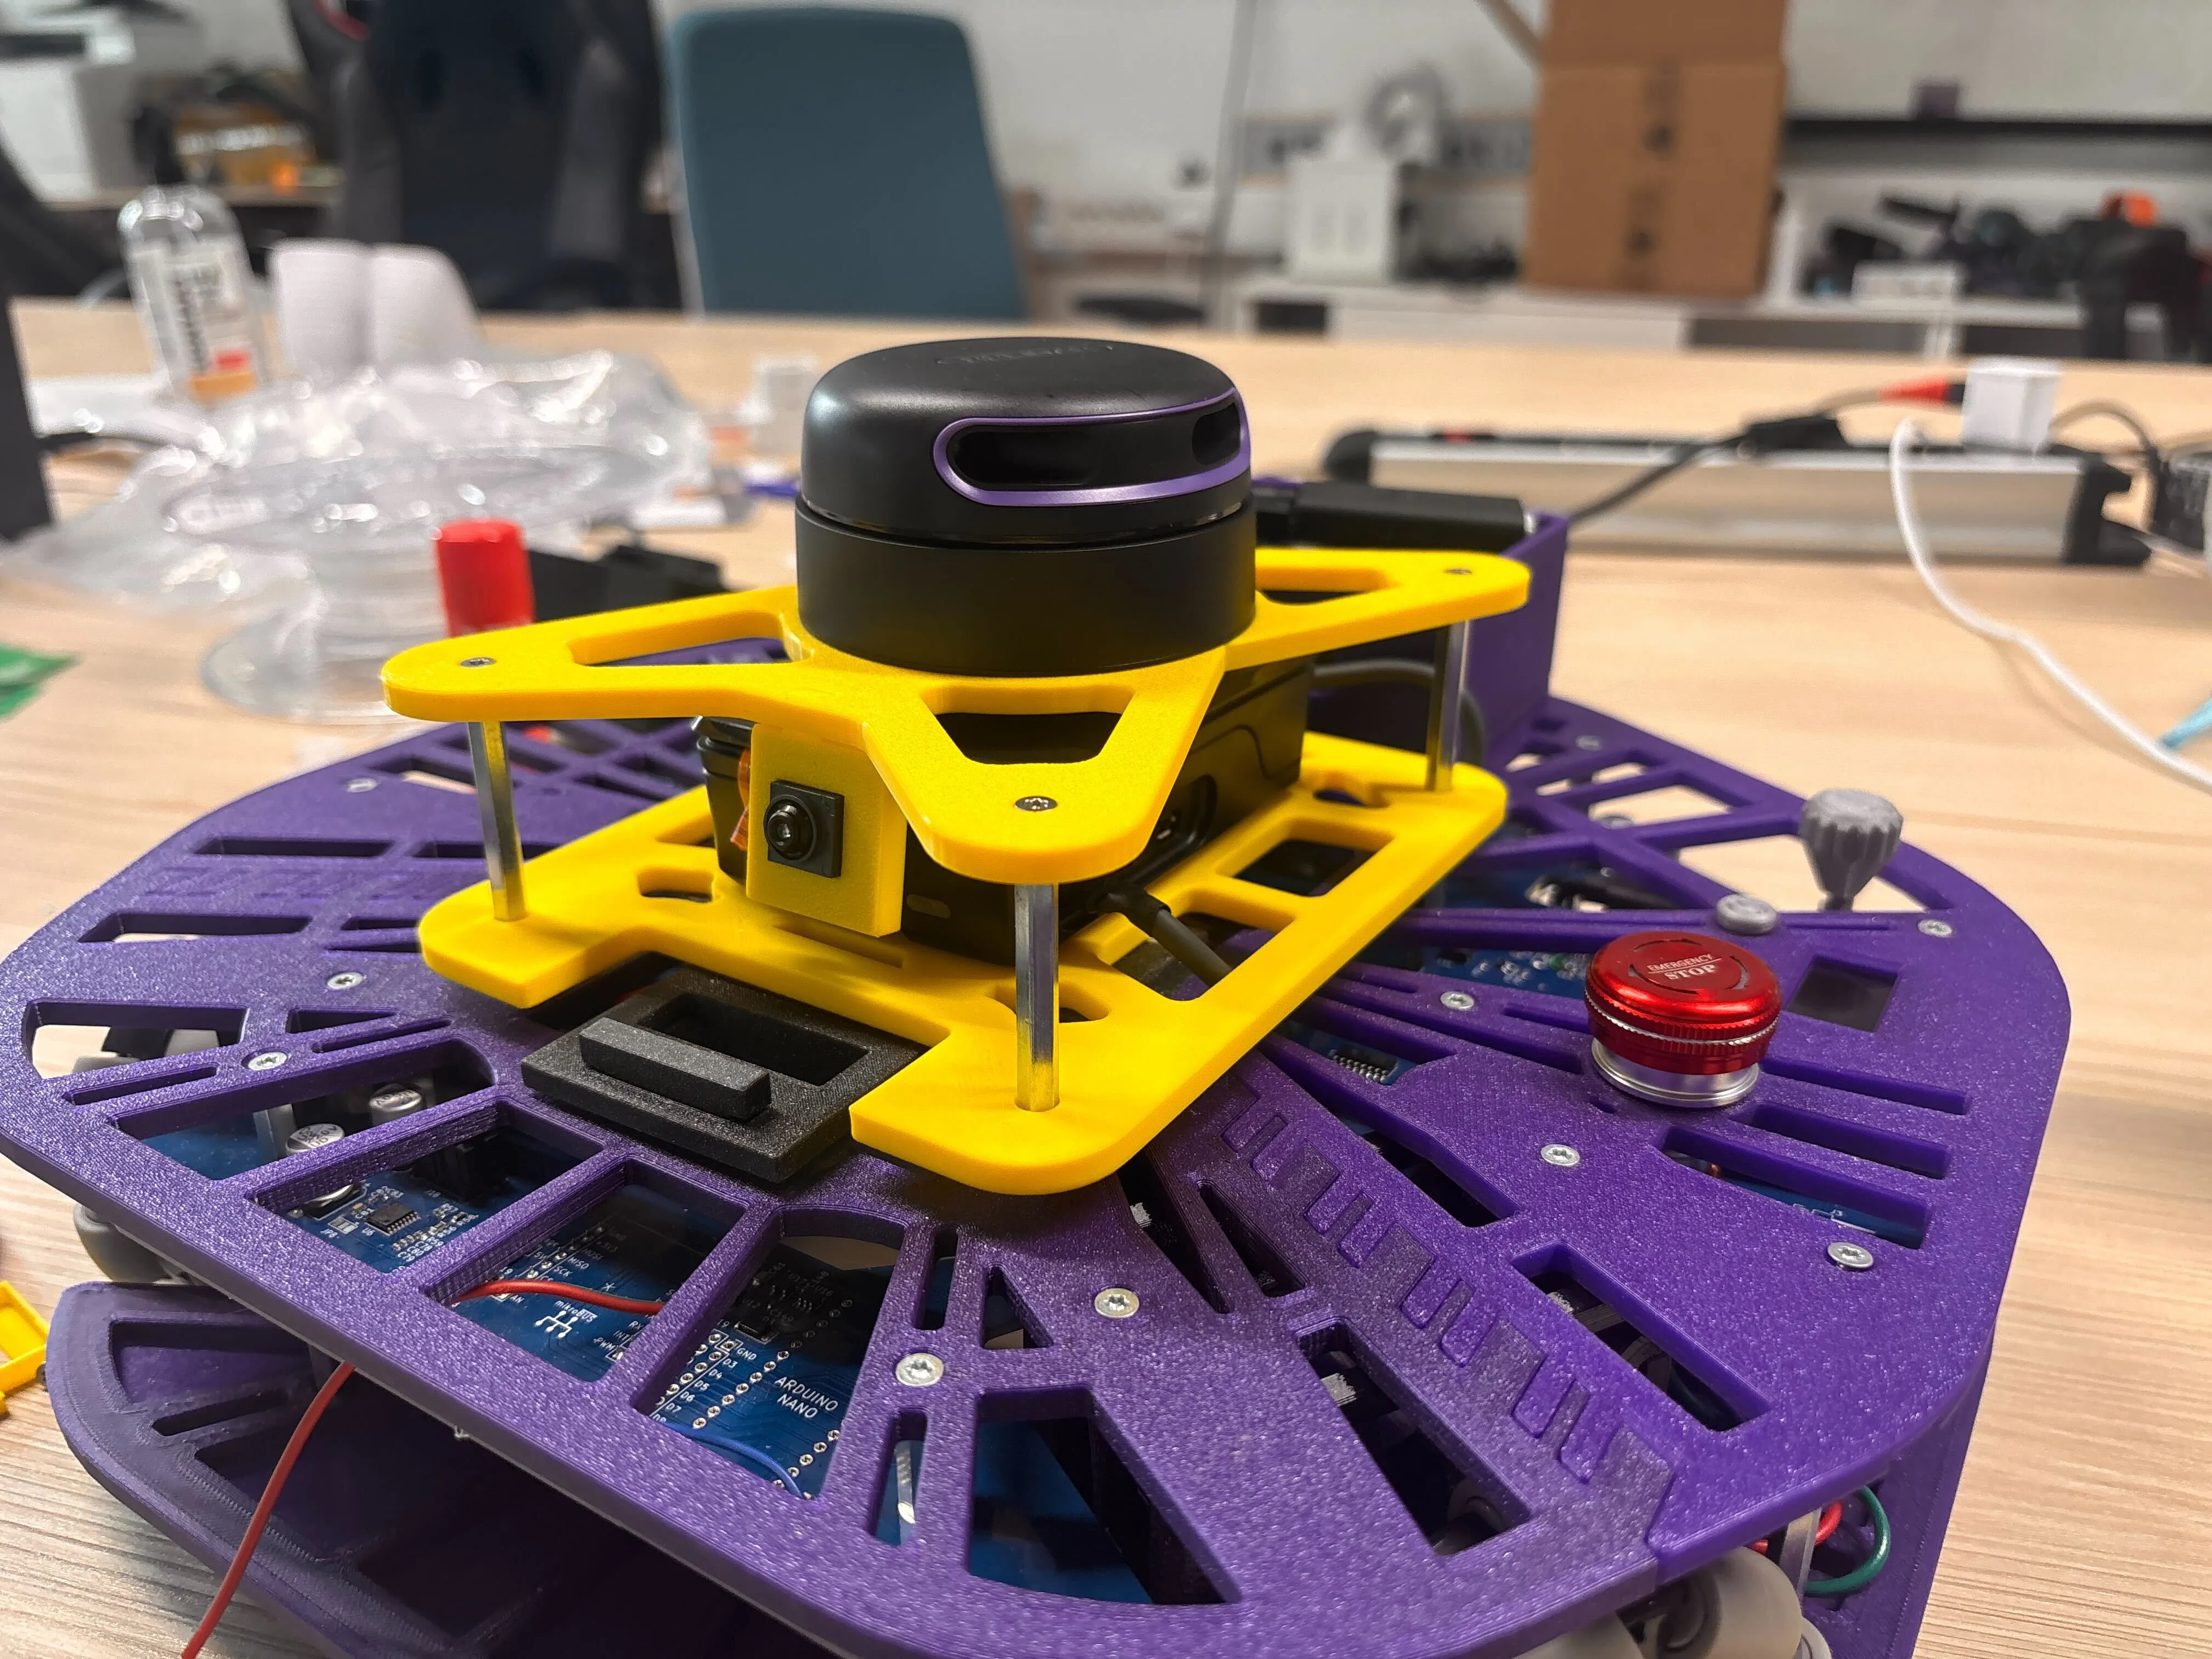
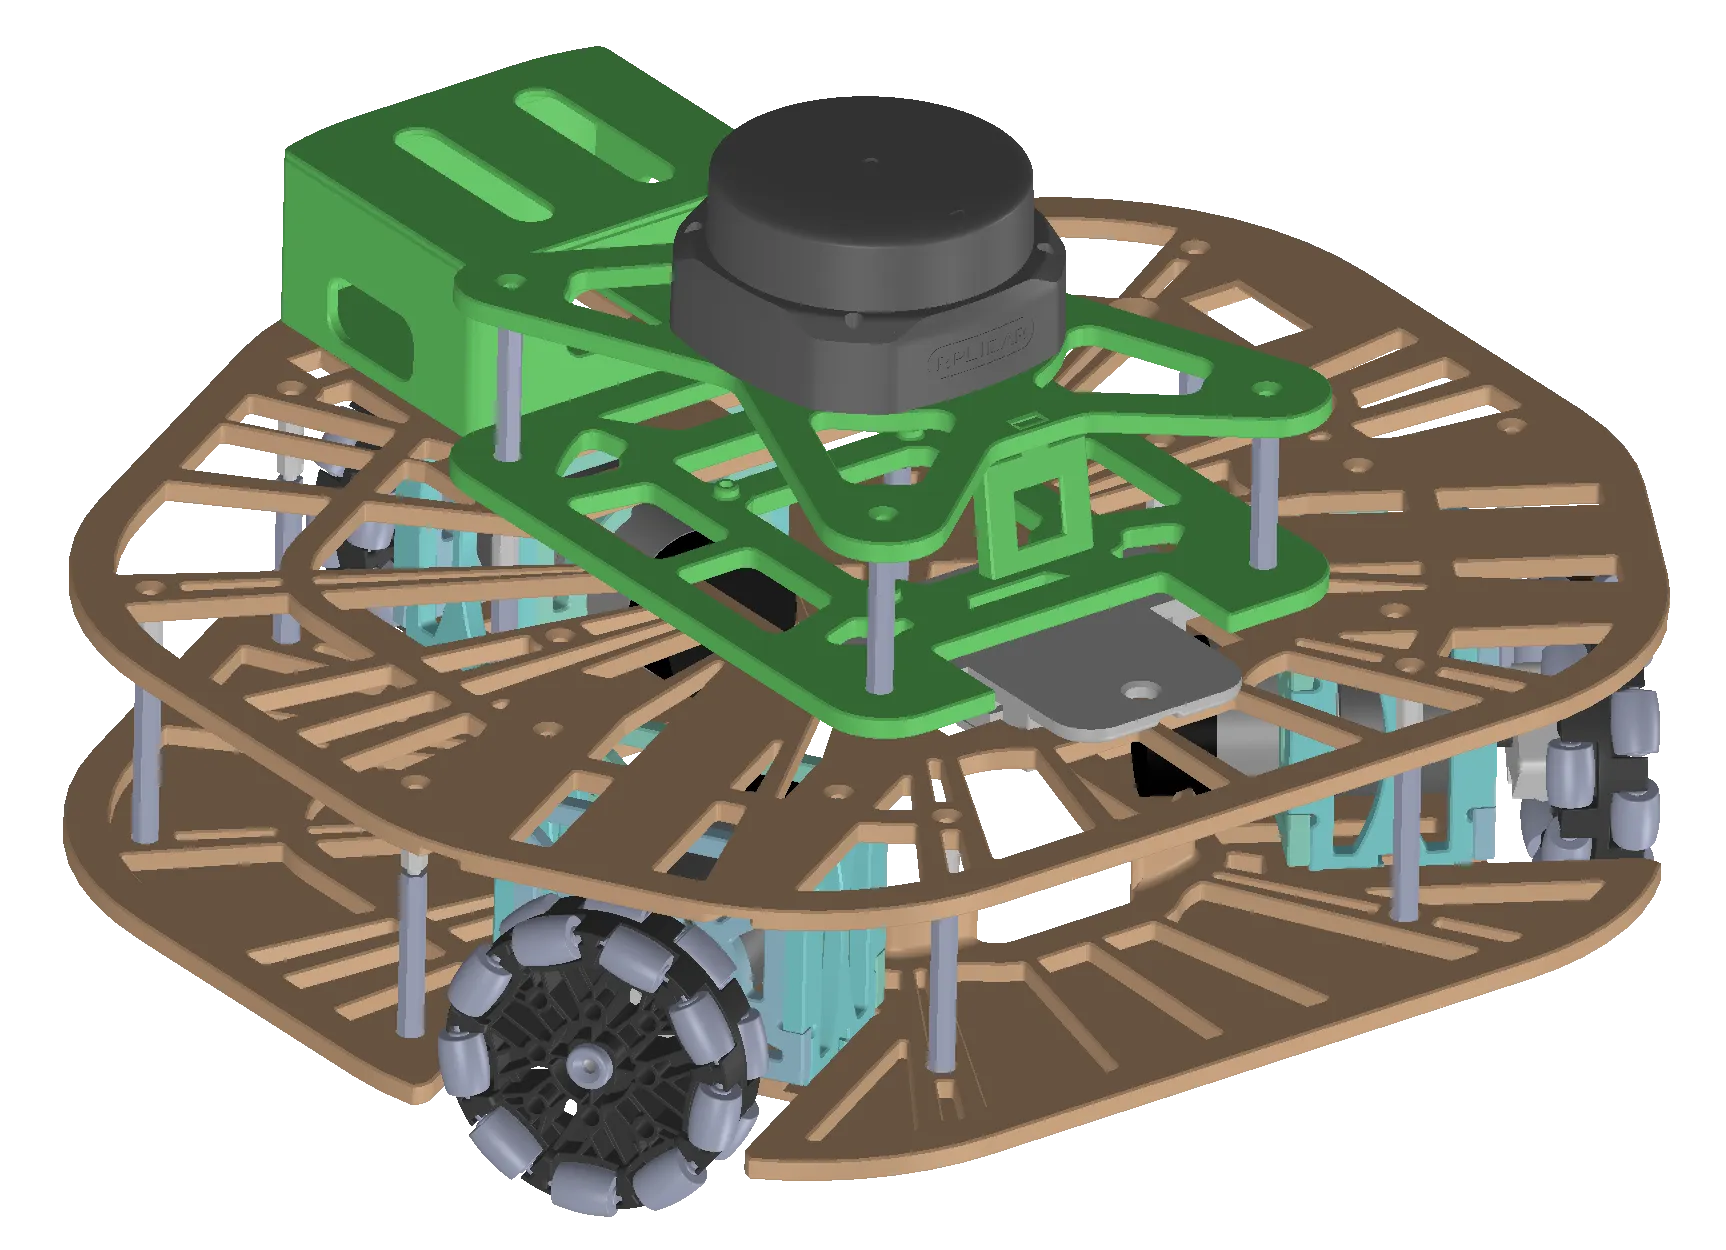
2026Robotont is an open-source mobile robotics platform from the University of Tartu. The Lite variant replaces the Intel NUC and RealSense camera with a Raspberry Pi 5, a Pi AI camera and a lidar. That cuts both the cost and the power draw. I reworked the Gen3 mechanics around the new hardware, kept the whole chassis 3D printable, and built a custom Ubuntu 24.04 kernel to support the Pi AI camera natively.
1 / 4
Through-Hole 65% Mechanical Keyboard
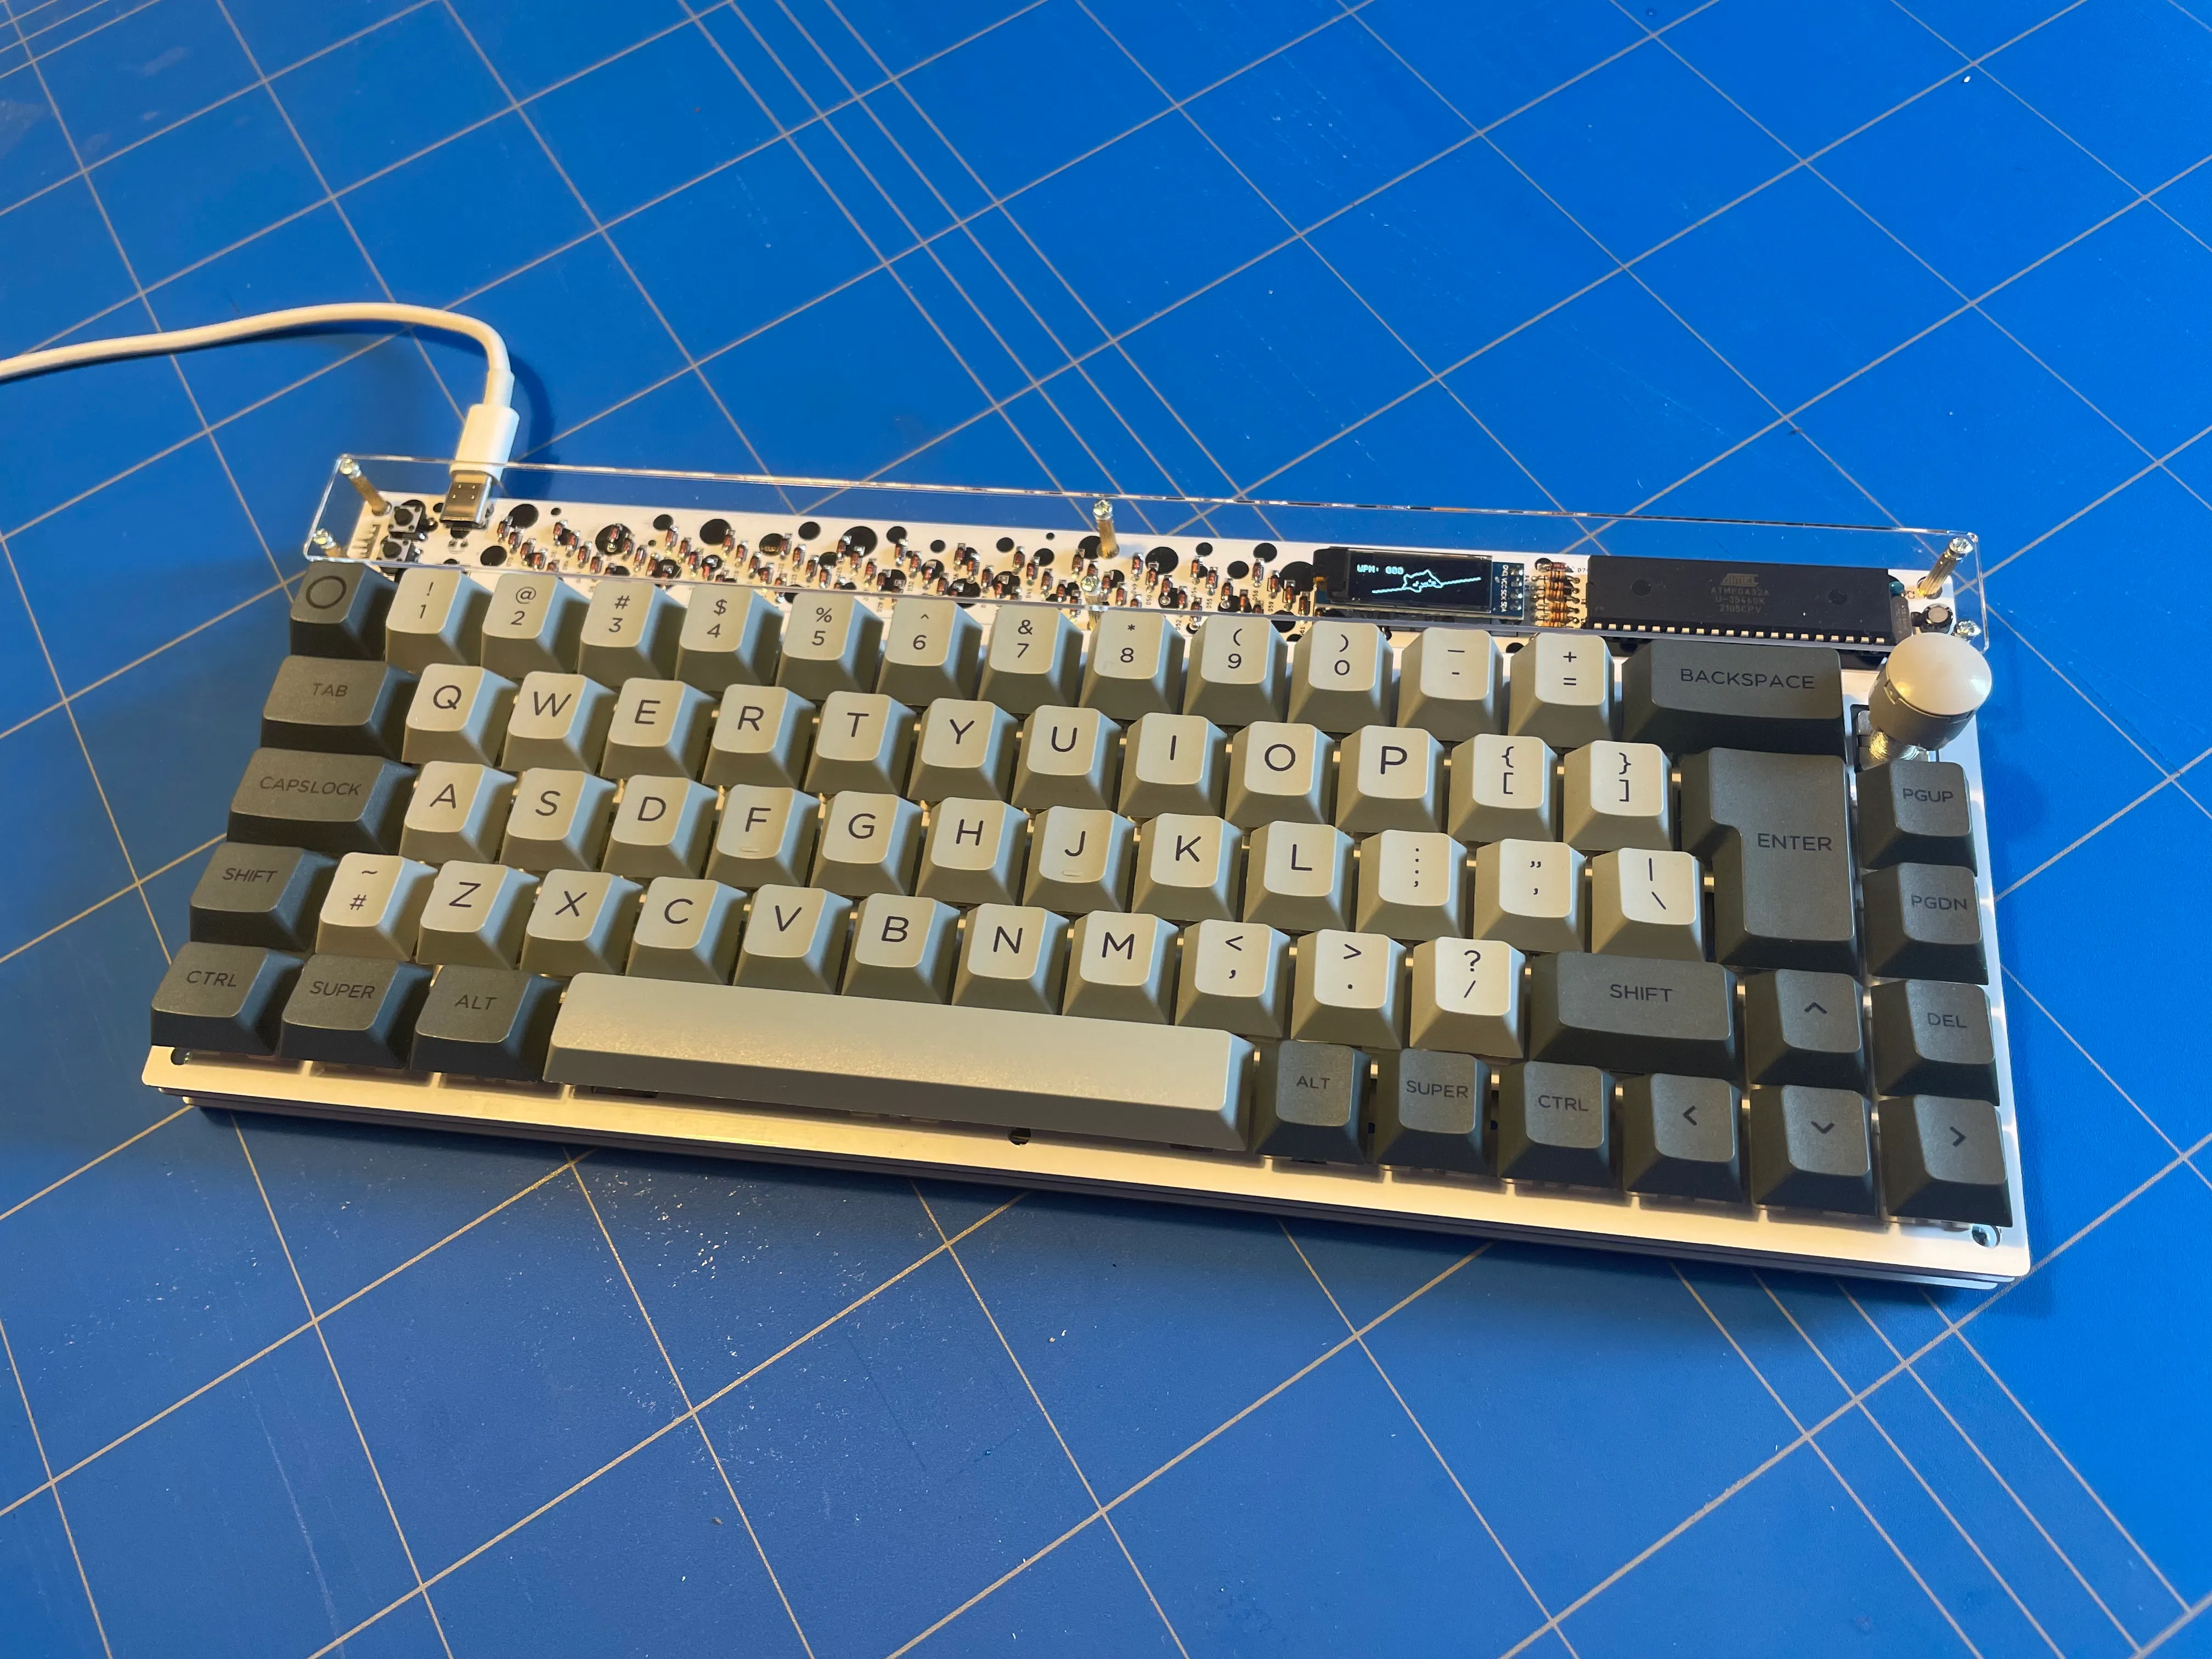
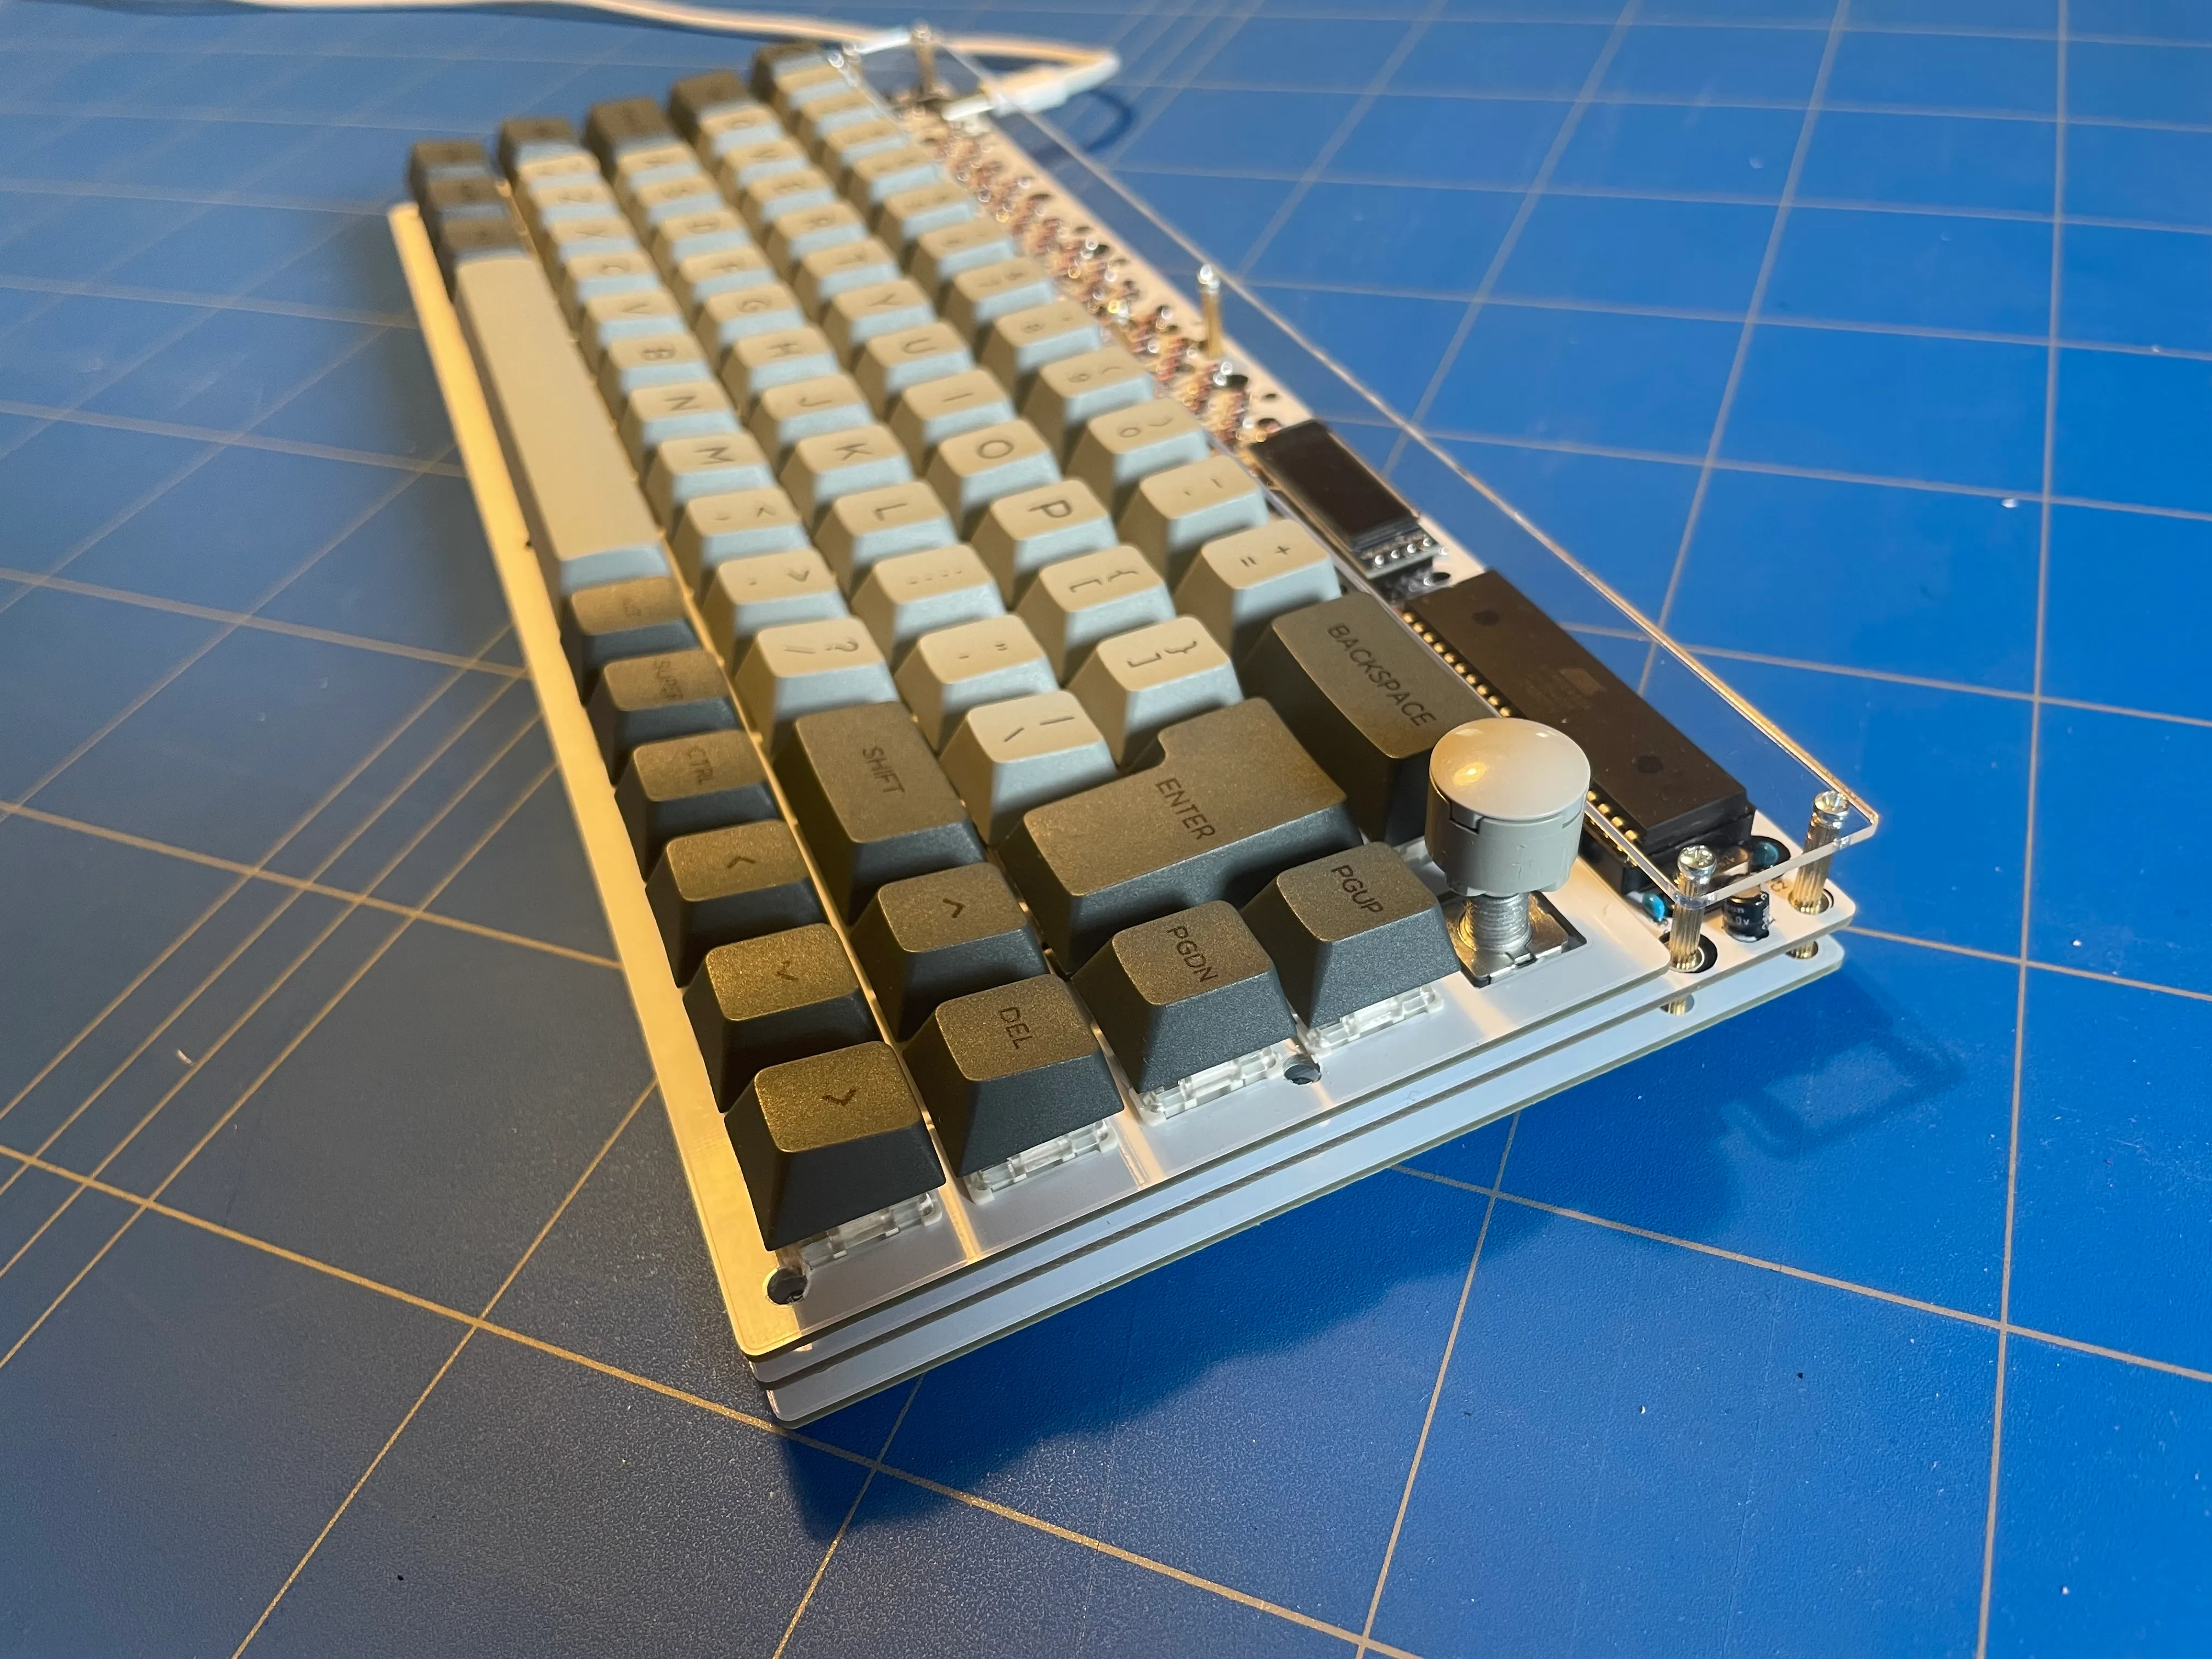
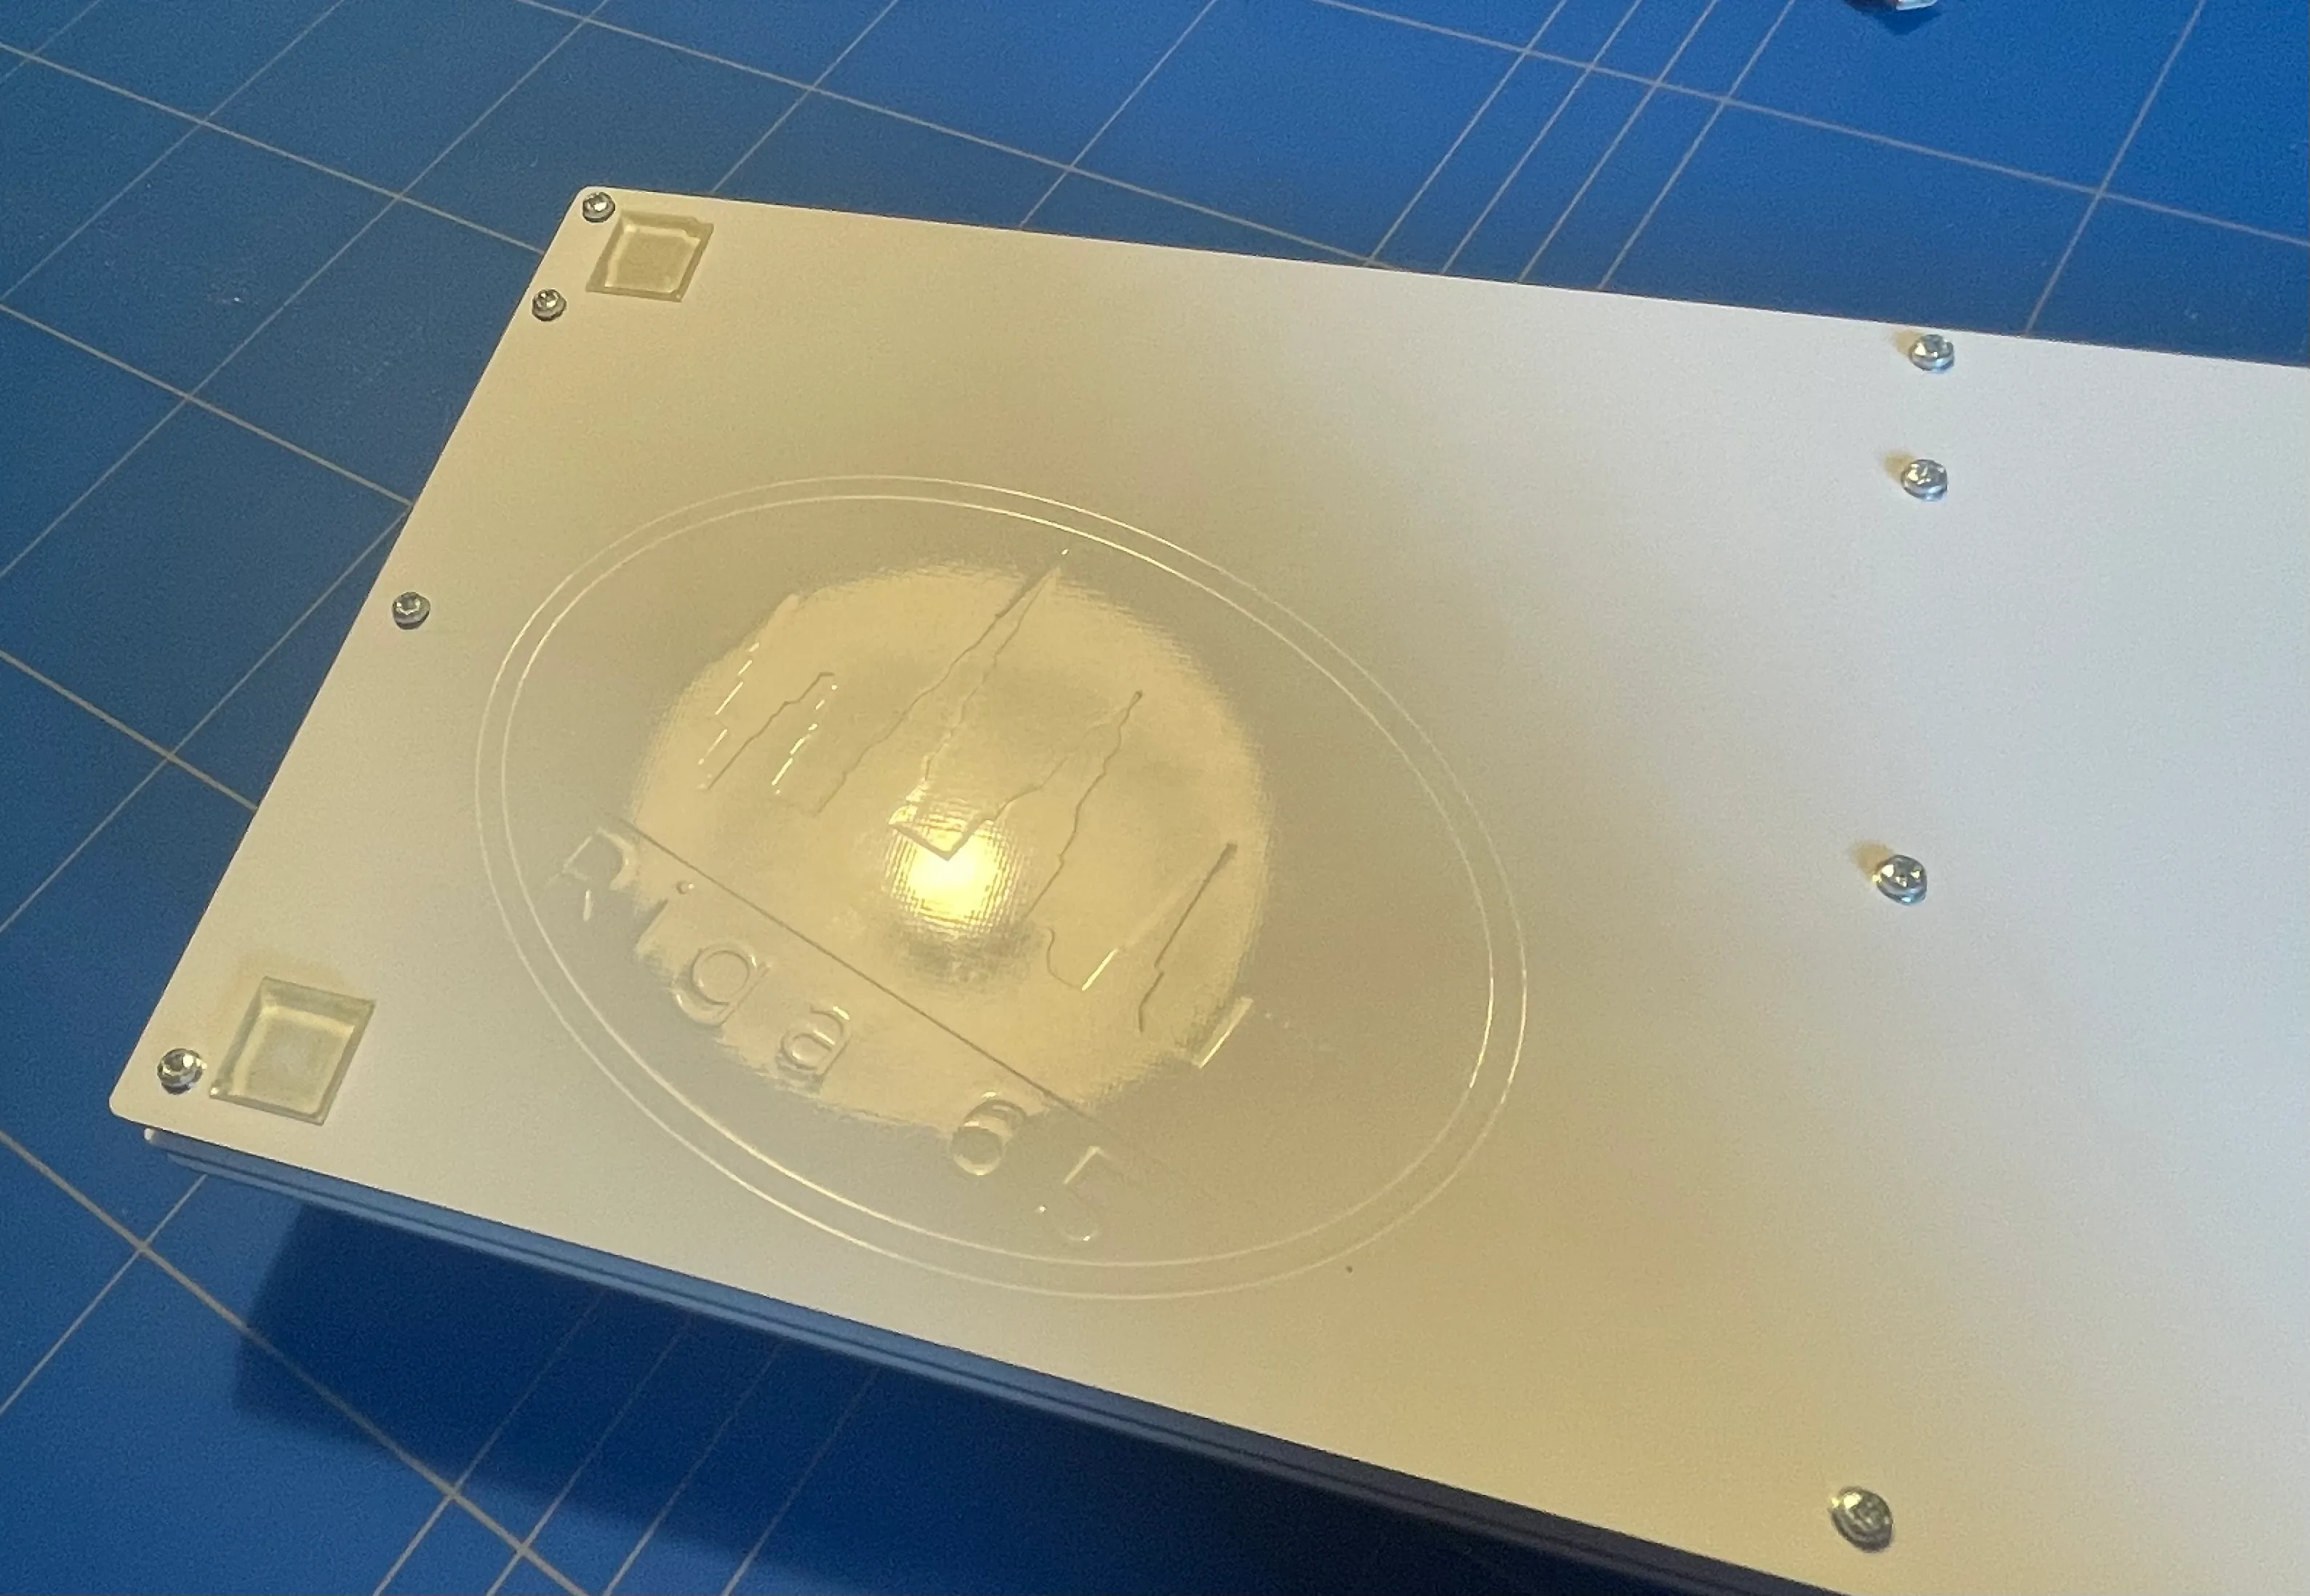
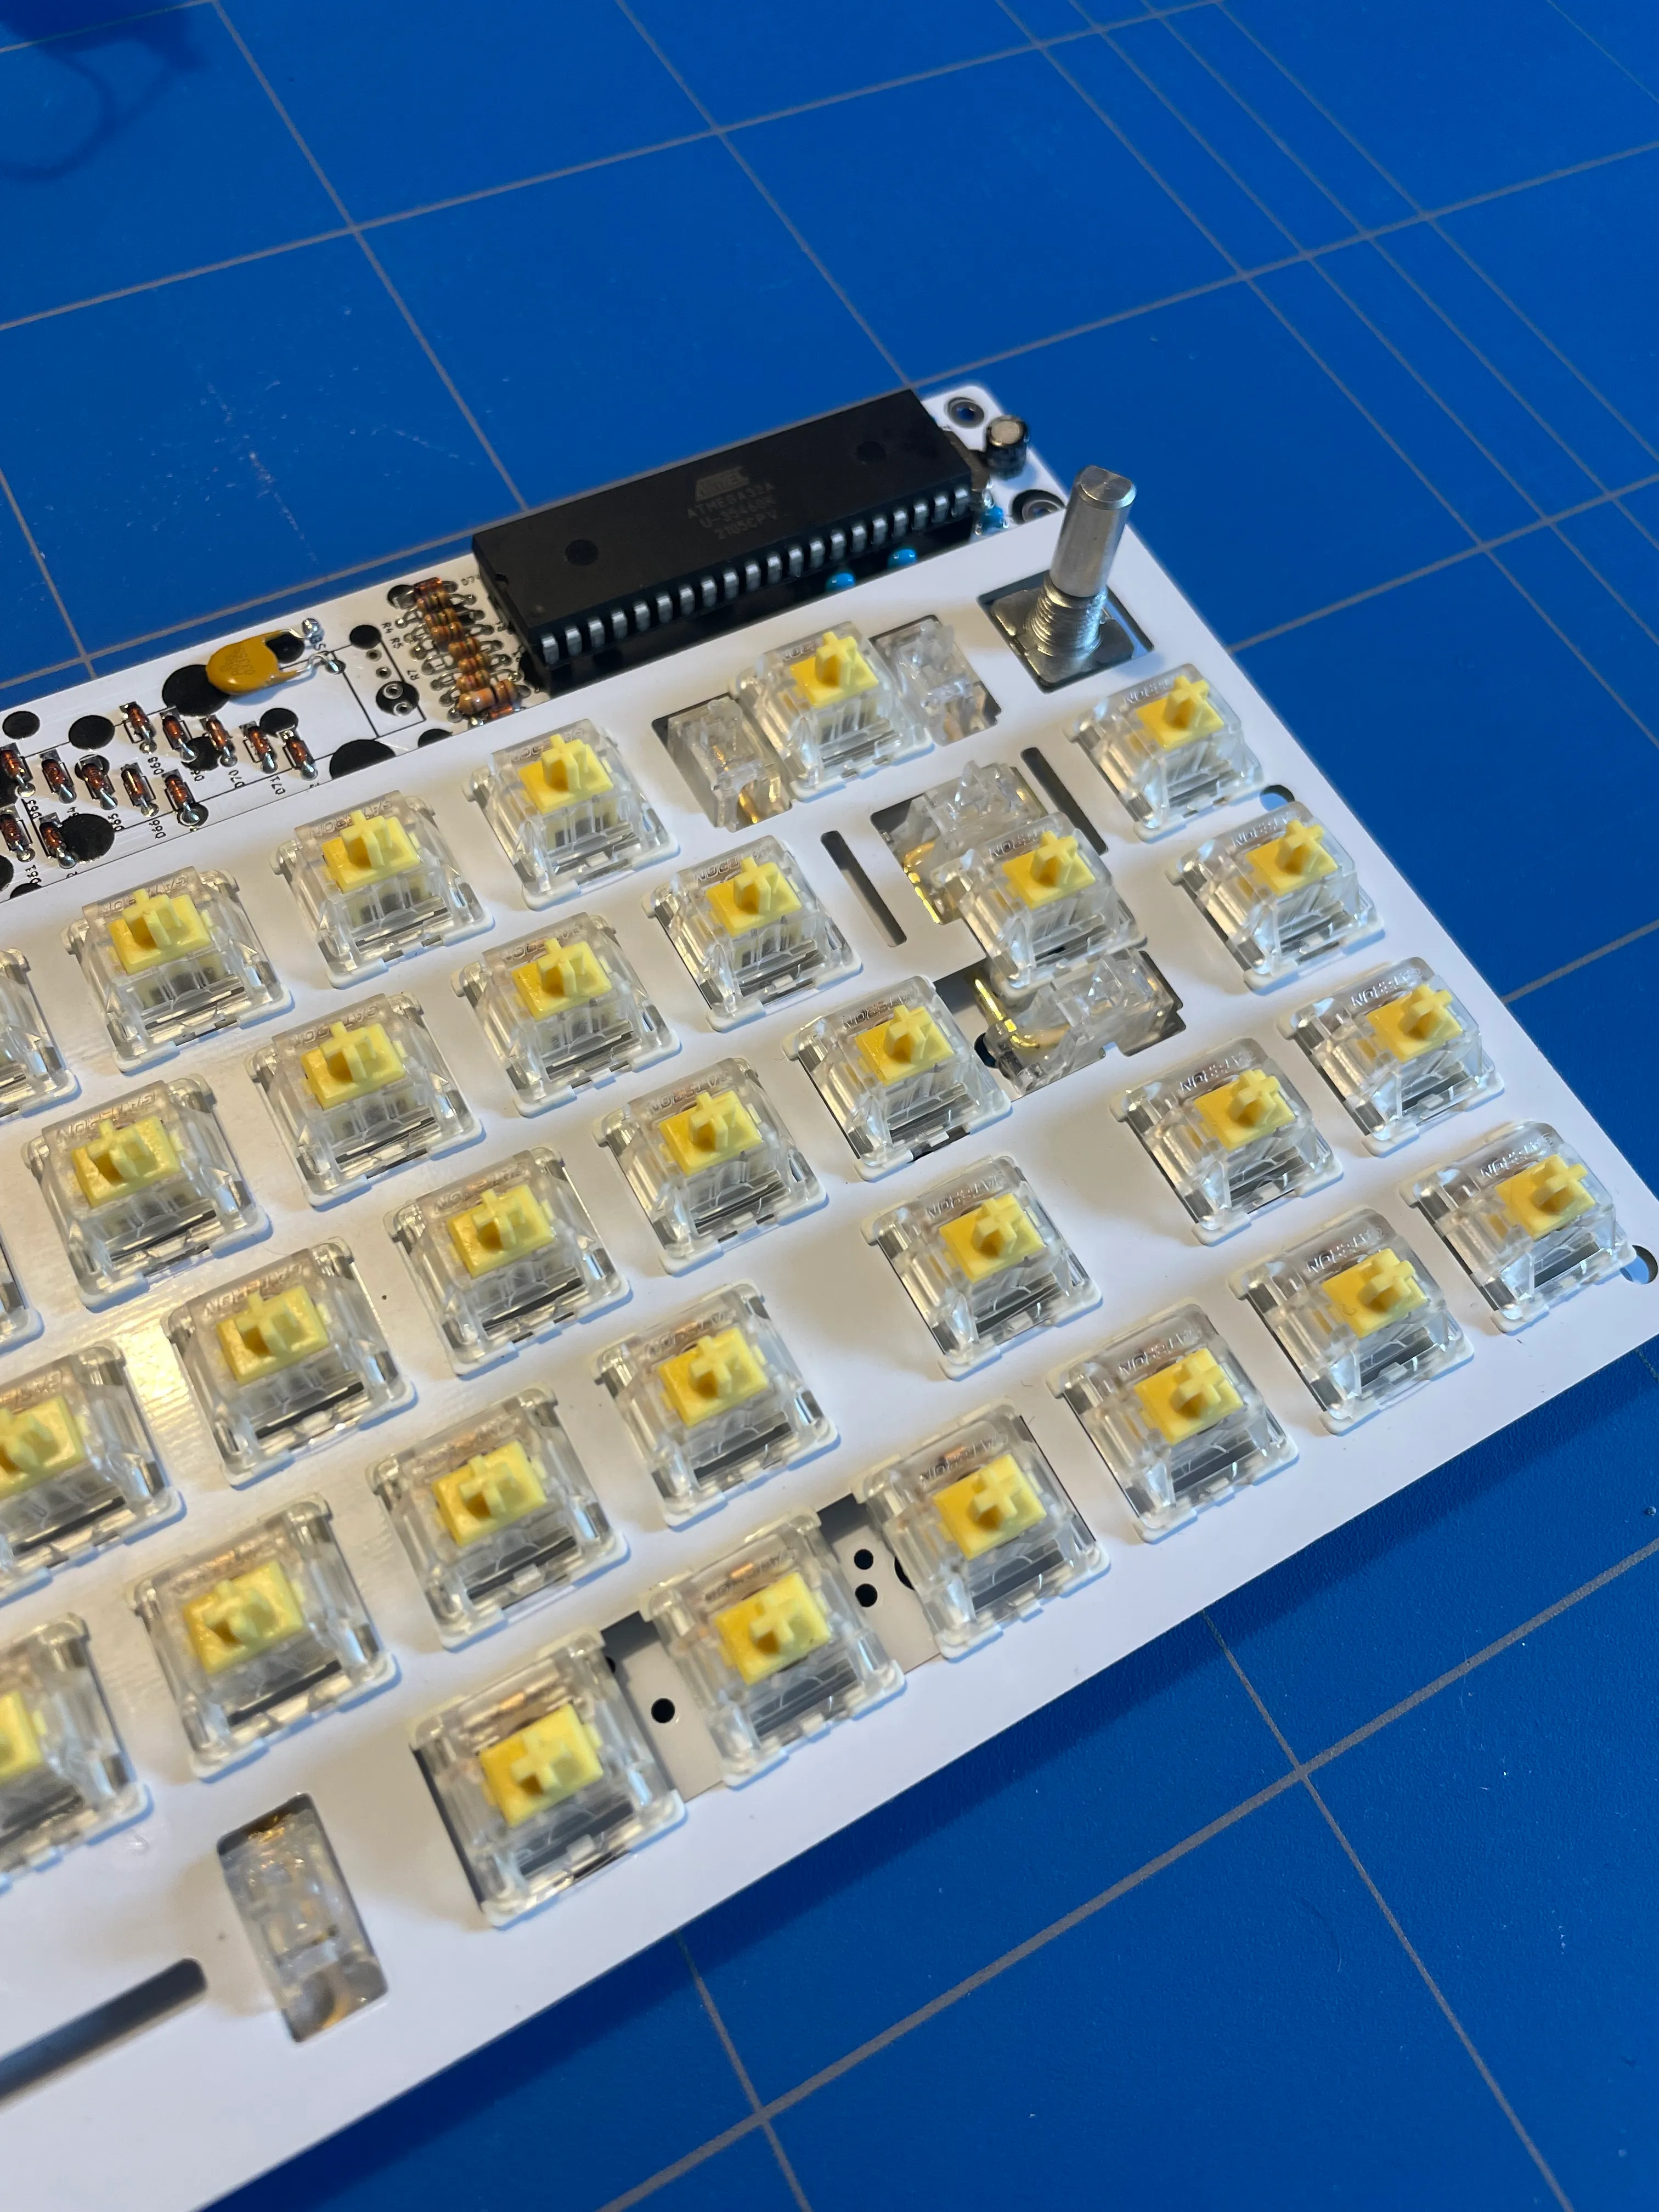
2022A 65% sandwich-mount mechanical keyboard I designed from scratch, running QMK on an ATmega32A. That chip has no native USB peripheral, so I ran the USB stack in software with V-USB. One PCB supports ISO and ANSI layouts plus several spacebar widths, with a rotary encoder and an OLED, both programmable in QMK. The back plate is embossed with the Riga skyline, my home city.
1 / 3
Ball Balancing Robot
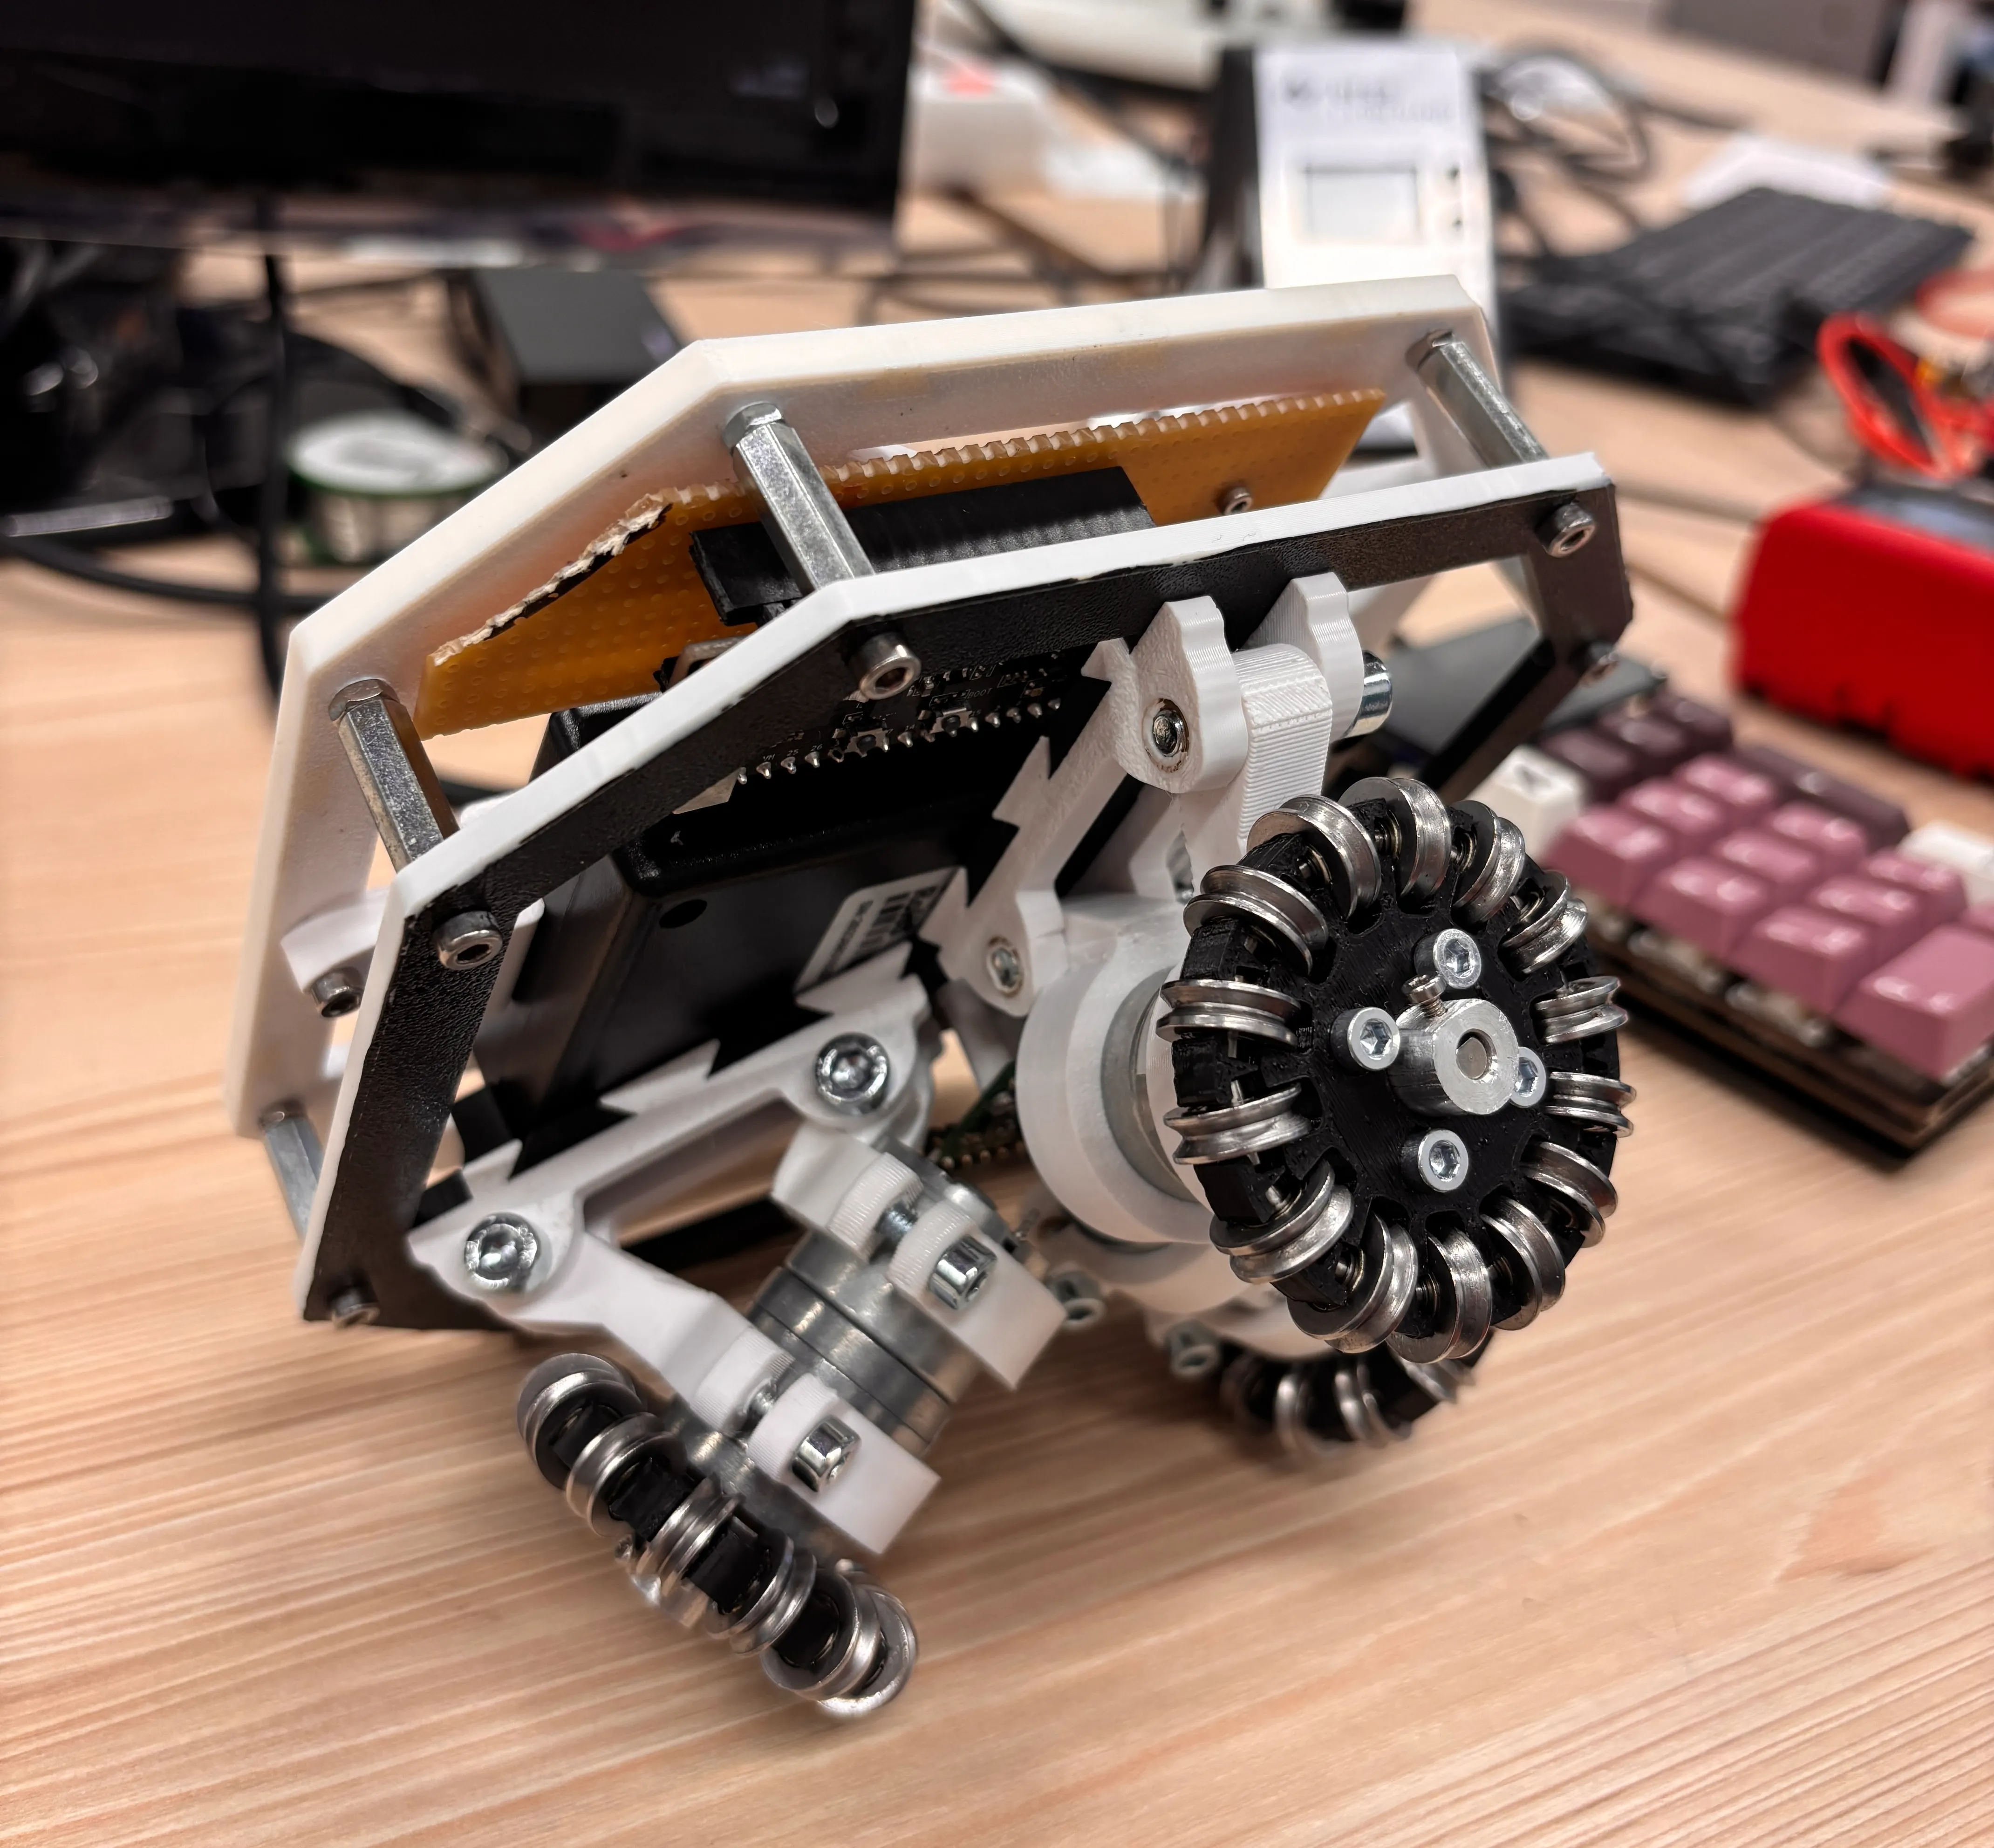
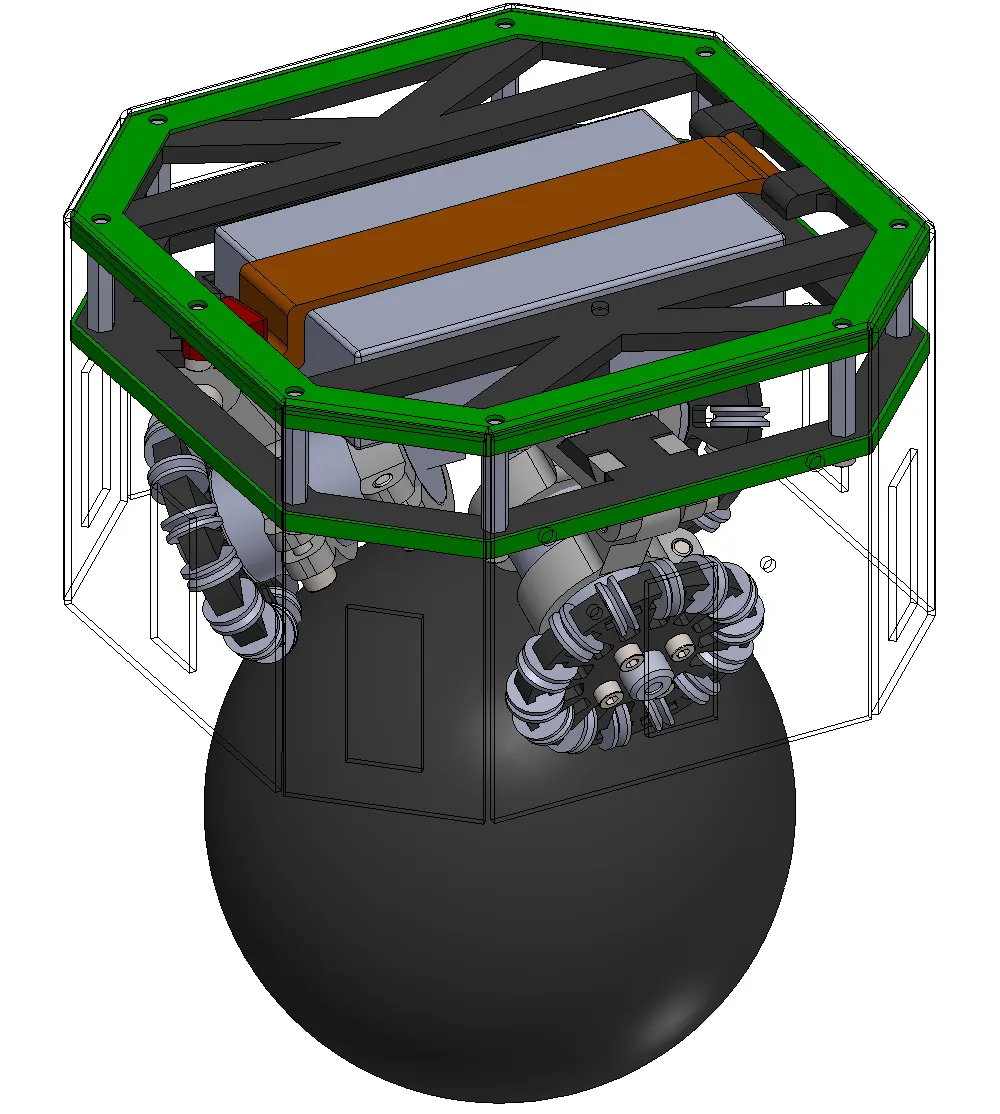
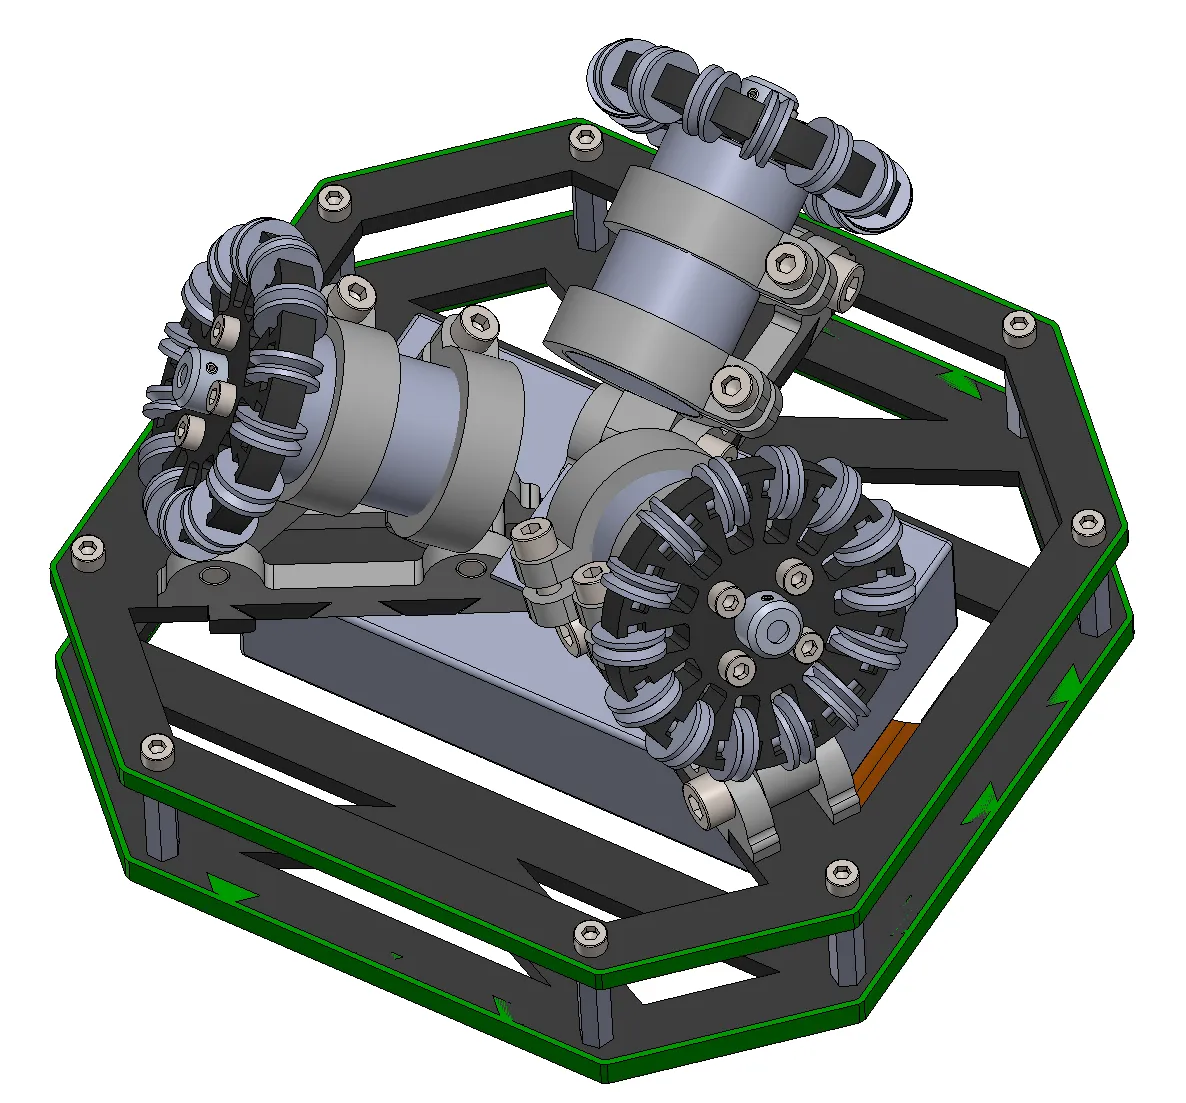
2025A robot that balances on top of a ball, driven by three omniwheels. I designed, built and programmed it: a 3D printed chassis and omniwheels, three brushed motors, and an ESP32-S3 running FreeRTOS. The balance loop reads the IMU and turns tilt into wheel speeds; a gamepad steers it while the loop keeps it upright.